

272
IX – Multivariate Differential and Integral Calculus
Ω
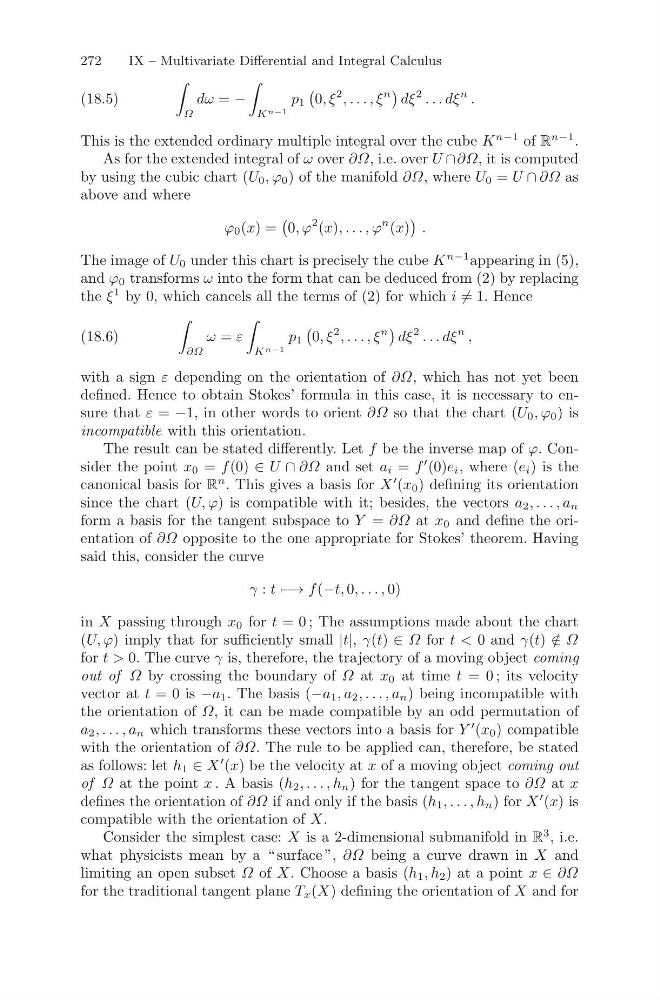
dω = −
K n−1
p 1
0, ξ
2 , . . . , ξ
n
dξ
2 . . . dξ
n .
(18.5)
This is the extended ordinary multiple integral over the cube K
n−1 of R
n−1 .
As for the extended integral of ω over ∂Ω, i.e. over U ∩ ∂Ω, it is computed
by using the cubic chart (U 0 , ϕ 0 ) of the manifold ∂Ω, where U 0 = U ∩ ∂Ω as
above and where
ϕ 0 (x) =
0, ϕ
2 (x), . . . , ϕ
n (x)
.
The image of U 0 under this chart is precisely the cube K
n−1 appearing in (5),
and ϕ 0 transforms ω into the form that can be deduced from (2) by replacing
the ξ
1 by 0, which cancels all the terms of (2) for which i = 1. Hence
∂Ω
ω = ε
K n−1
p 1
0, ξ
2 , . . . , ξ
n
dξ
2 . . . dξ
n ,
(18.6)
with a sign ε depending on the orientation of ∂Ω, which has not yet been
defined. Hence to obtain Stokes’ formula in this case, it is necessary to ensure that ε = −1, in other words to orient ∂Ω so that the chart (U 0 , ϕ 0 ) is
incompatible with this orientation.
The result can be stated differently. Let f be the inverse map of ϕ. Consider the point x 0 = f (0) ∈ U ∩ ∂Ω and set a i = f
(0)e i , where (e i ) is the
canonical basis for R
n . This gives a basis for X
(x 0 ) defining its orientation
since the chart (U, ϕ) is compatible with it; besides, the vectors a 2 , . . . , a n
form a basis for the tangent subspace to Y = ∂Ω at x 0 and define the orientation of ∂Ω opposite to the one appropriate for Stokes’ theorem. Having
said this, consider the curve
γ : t −→ f (−t, 0, . . . , 0)
in X passing through x 0 for t = 0 ; The assumptions made about the chart
(U, ϕ) imply that for sufficiently small |t|, γ(t) ∈ Ω for t < 0 and γ(t) /
∈ Ω
for t > 0. The curve γ is, therefore, the trajectory of a moving object coming
out of Ω by crossing the boundary of Ω at x 0 at time t = 0 ; its velocity
vector at t = 0 is −a 1 . The basis (−a 1 , a 2 , . . . , a n ) being incompatible with
the orientation of Ω, it can be made compatible by an odd permutation of
a 2 , . . . , a n which transforms these vectors into a basis for Y
(x 0 ) compatible
with the orientation of ∂Ω. The rule to be applied can, therefore, be stated
as follows: let h 1 ∈ X
(x) be the velocity at x of a moving object coming out
of Ω at the point x . A basis (h 2 , . . . , h n ) for the tangent space to ∂Ω at x
defines the orientation of ∂Ω if and only if the basis (h 1 , . . . , h n ) for X
(x) is
compatible with the orientation of X.
Consider the simplest case: X is a 2-dimensional submanifold in R
3 , i.e.
what physicists mean by a “ surface ”, ∂Ω being a curve drawn in X and
limiting an open subset Ω of X. Choose a basis (h 1 , h 2 ) at a point x ∈ ∂Ω
for the traditional tangent plane T x (X) defining the orientation of X and for