

70
1 From Riemann manifolds to Riemann manifolds
Solution (the third problem).
By means of the two mapping equations “left” {P = f (Φ) cos Λ, Q = f (Φ) sin Λ} and of the two
mapping equations “right” {p = g(φ) cos λ, q = g(φ) sin λ}, we are able to compute the factors of
conformality {Λ
2
l , λ
2
l } of type “left” and {Λ
2
r , λ
2
r } of type “right”. The detailed formulae are reviewed
in Box 1.34. If we specify “left” Φ = π/2 (ellipsoidal North Pole) or “right” φ = π/2 (spherical North
Pole), we are led to l Λ
2
1 (π/2) = l Λ
2
2 (π/2) = Λ
2
l (π/2) = 1 and r Λ
2
1 (π/2) = r Λ
2
2 (π/2) = Λ
2
r (π/2) = 1.
Obviously, at the North Pole, “left UPS” and “right UPS” are an isometry. We shall see later that
this is a built-in constraint for any UPS.
End of Solution (the third problem).
Solution (the fourth problem).
A “simple conformal mapping” of E
2
A 1 ,A 1 ,A 2
→ S
2
r is the isoparametric mapping, which is conveniently
characterized by
p = P , q = Q or
2r tan
π
4 −
φ
2
cos λ =
2A 1
√
1−E 2
(1−E)
E/2
(1+E) E/2 tan
π
4 −
Φ
2
1+E sin Φ
1−E sin Φ
E/2
cos Λ ,
2r tan
π
4 −
φ
2
sin λ =
2A 1
√
1−E 2
(1−E)
E/2
(1+E) E/2 tan
π
4 −
Φ
2
1+E sin Φ
1−E sin Φ
E/2
sin Λ .
(1.258)
Here, we conclude with a representation of the left as well as the right inverse mapping, namely
Φ
−1
l
: {P, Q} → X(P, Q) and Φ
−1
r
: {p, q} → x(p, q) in terms of conformal coordinates (isometric,
isothermal) of Box 1.37, which specializes Φ
−1
l
and Φ
−1
r
of Box 1.21.
End of Solution (the fourth problem).
Solution (the fifth problem).
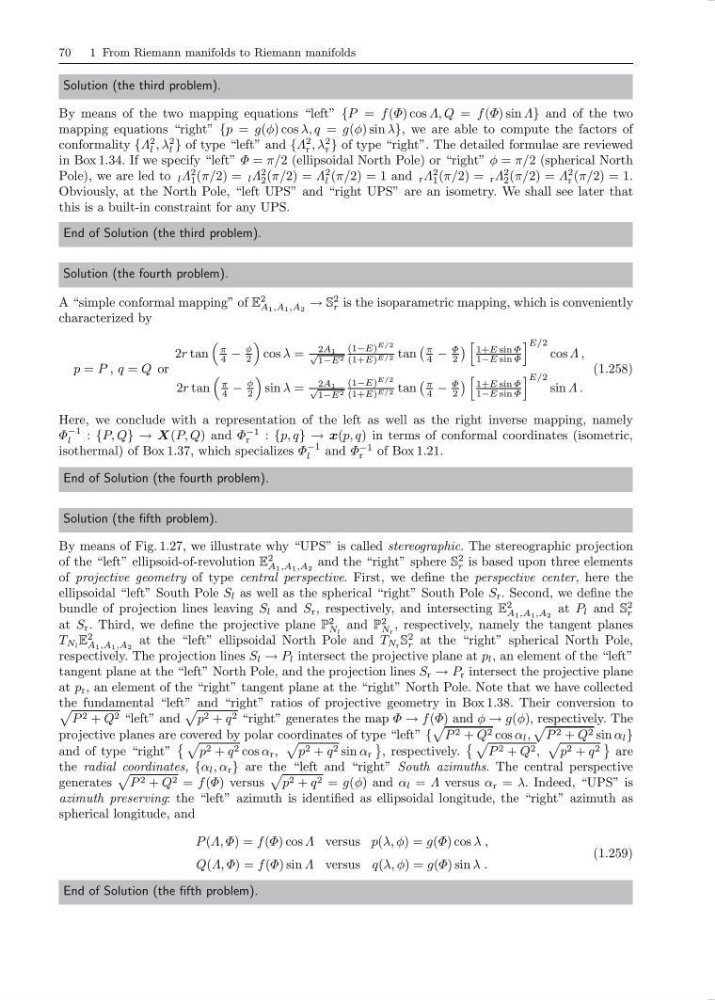
By means of Fig. 1.27, we illustrate why “UPS” is called stereographic. The stereographic projection
of the “left” ellipsoid-of-revolution E
2
A 1 ,A 1 ,A 2
and the “right” sphere S
2
r is based upon three elements
of projective geometry of type central perspective. First, we define the perspective center, here the
ellipsoidal “left” South Pole S l as well as the spherical “right” South Pole S r . Second, we define the
bundle of projection lines leaving S l and S r , respectively, and intersecting E
2
A 1 ,A 1 ,A 2
at P l and S
2
r
at S r . Third, we define the projective plane P
2
N l
and P
2
N r
, respectively, namely the tangent planes
T N l E
2
A 1 ,A 1 ,A 2
at the “left” ellipsoidal North Pole and T N r S
2
r at the “right” spherical North Pole,
respectively. The projection lines S l → P l intersect the projective plane at p l , an element of the “left”
tangent plane at the “left” North Pole, and the projection lines S r → P r intersect the projective plane
at p r , an element of the “right” tangent plane at the “right” North Pole. Note that we have collected
the fundamental “left” and “right” ratios of projective geometry in Box 1.38. Their conversion to
P 2 + Q 2 “left” and
p 2 + q 2 “right” generates the map Φ → f (Φ) and φ → g(φ), respectively. The
projective planes are covered by polar coordinates of type “left” {
P 2 + Q 2 cos α l ,
P 2 + Q 2 sin α l }
and of type “right”
p 2 + q 2 cos α r ,
p 2 + q 2 sin α r
, respectively.
P 2 + Q 2 ,
p 2 + q 2
are
the radial coordinates, {α l , α r } are the “left and “right” South azimuths. The central perspective
generates
P 2 + Q 2 = f (Φ) versus
p 2 + q 2 = g(φ) and α l = Λ versus α r = λ. Indeed, “UPS” is
azimuth preserving: the “left” azimuth is identified as ellipsoidal longitude, the “right” azimuth as
spherical longitude, and
P (Λ, Φ) = f (Φ) cos Λ versus p(λ, φ) = g(Φ) cos λ ,
Q(Λ, Φ) = f (Φ) sin Λ versus q(λ, φ) = g(Φ) sin λ .
(1.259)
End of Solution (the fifth problem).