

Preface
This book is dedicated to the Memory
of US GS’s J. P. Snyder (1926–1997),
genius of inventing new Map Projections.
Our review of Map Projections has 21 chapters and 10 appendices. Let us point out the most essential
details in advance in the following passages.
Foundations.
The first four chapters are of purely introductory nature. Chapter 1 and Chapter 2 are concerned with
general mappings from Riemann manifolds to Riemann manifolds and with general mappings from
Riemann manifolds to Euclidean manifolds and present the important eigenspace analysis of types
Cauchy–Green and Euler–Lagrange. Chapter 3 introduces coordinates or parameters of a Riemann
manifold, Killing vectors of symmetry, and oblique frames of reference for the sphere and for the
ellipsoid-of-revolution. A special topic is the classification of surfaces of zero Gaussian curvature for
ruled surfaces and for developable surfaces in Chapter 4.
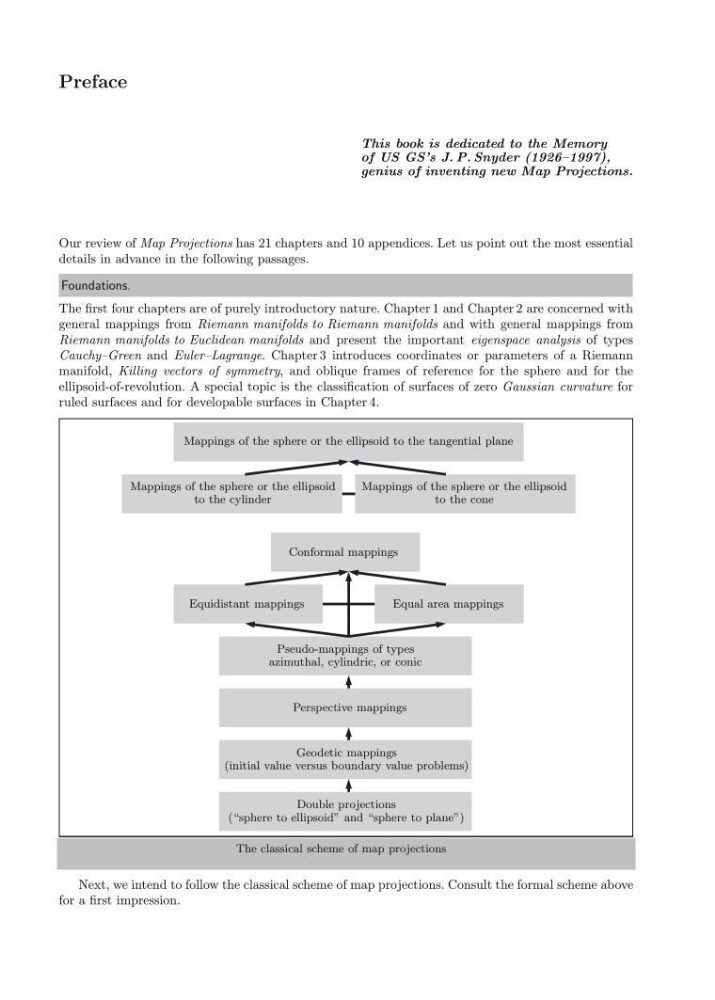
Mappings of the sphere or the ellipsoid to the tangential plane
Mappings of the sphere or the ellipsoid
to the cylinder
Mappings of the sphere or the ellipsoid
to the cone
Conformal mappings
Equidistant mappings
Equal area mappings
Pseudo-mappings of types
azimuthal, cylindric, or conic
Perspective mappings
Geodetic mappings
(initial value versus boundary value problems)
Double projections
(“sphere to ellipsoid” and “sphere to plane”)
The classical scheme of map projections
Next, we intend to follow the classical scheme of map projections. Consult the formal scheme above
for a first impression.