

1-3 Two examples: pseudo-cylindrical and orthogonal map projections 21
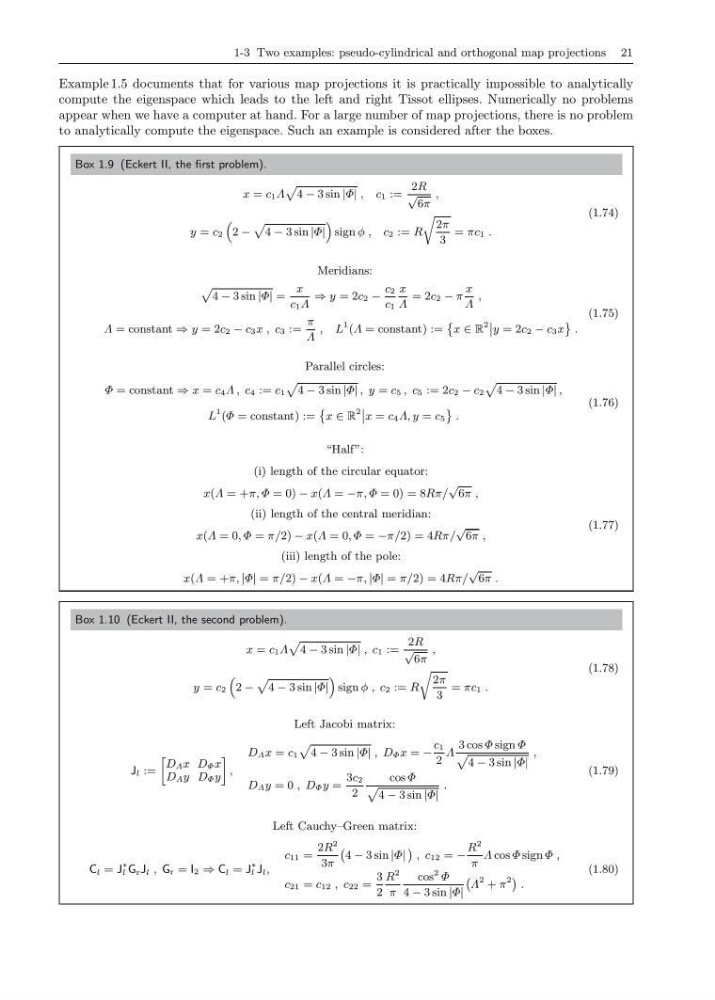
Example 1.5 documents that for various map projections it is practically impossible to analytically
compute the eigenspace which leads to the left and right Tissot ellipses. Numerically no problems
appear when we have a computer at hand. For a large number of map projections, there is no problem
to analytically compute the eigenspace. Such an example is considered after the boxes.
Box 1.9 (Eckert II, the first problem).
x = c 1 Λ
p
4 − 3 sin |Φ| , c 1 :=
2R
√
6π
,
y = c 2
“
2 −
p
4 − 3 sin |Φ|
”
sign φ , c 2 := R
r
2π
3
= πc 1 .
(1.74)
Meridians:
p
4 − 3 sin |Φ| =
x
c 1 Λ
⇒ y = 2c 2 −
c 2
c 1
x
Λ
= 2c 2 − π
x
Λ
,
Λ = constant ⇒ y = 2c 2 − c 3 x , c 3 :=
π
Λ
, L
1 (Λ = constant) :=
˘
x ∈ R
2
˛
˛ y = 2c 2 − c 3 x
¯
.
(1.75)
Parallel circles:
Φ = constant ⇒ x = c 4 Λ , c 4 := c 1
p
4 − 3 sin |Φ| , y = c 5 , c 5 := 2c 2 − c 2
p
4 − 3 sin |Φ| ,
L
1 (Φ = constant) :=
˘
x ∈ R
2
˛
˛ x = c 4 Λ, y = c 5
¯
.
(1.76)
“Half”:
(i) length of the circular equator:
x(Λ = +π, Φ = 0) − x(Λ = −π, Φ = 0) = 8Rπ/
√
6π ,
(ii) length of the central meridian:
x(Λ = 0, Φ = π/2) − x(Λ = 0, Φ = −π/2) = 4Rπ/
√
6π ,
(iii) length of the pole:
x(Λ = +π, |Φ| = π/2) − x(Λ = −π, |Φ| = π/2) = 4Rπ/
√
6π .
(1.77)
Box 1.10 (Eckert II, the second problem).
x = c 1 Λ
p
4 − 3 sin |Φ| , c 1 :=
2R
√
6π
,
y = c 2
“
2 −
p
4 − 3 sin |Φ|
”
sign φ , c 2 := R
r
2π
3
= πc 1 .
(1.78)
Left Jacobi matrix:
J l :=
»
D Λ x D Φ x
D Λ y D Φ y
–
,
D Λ x = c 1
p
4 − 3 sin |Φ| , D Φ x = −
c 1
2
Λ
3 cos Φ sign Φ
p
4 − 3 sin |Φ|
,
D Λ y = 0 , D Φ y =
3c 2
2
cos Φ
p
4 − 3 sin |Φ|
.
(1.79)
Left Cauchy–Green matrix:
C l = J
∗
l G r J l , G r = I 2 ⇒ C l = J
∗
l J l ,
c 11 =
2R
2
3π
`
4 − 3 sin |Φ|
´
, c 12 = −
R
2
π
Λ cos Φ sign Φ ,
c 21 = c 12 , c 22 =
3
2
R
2
π
cos
2 Φ
4 − 3 sin |Φ|
`
Λ
2 + π
2 ´
.
(1.80)