

14-3 General cylindric mappings (equidistant, rotational-symmetric figure) 307
14-3 General cylindric mappings (equidistant, rotational-symmetric figure)
General mapping equations and distortion measures of cylindric mappings of type equidistant mappings
in case of a rotationally symmetric figure.
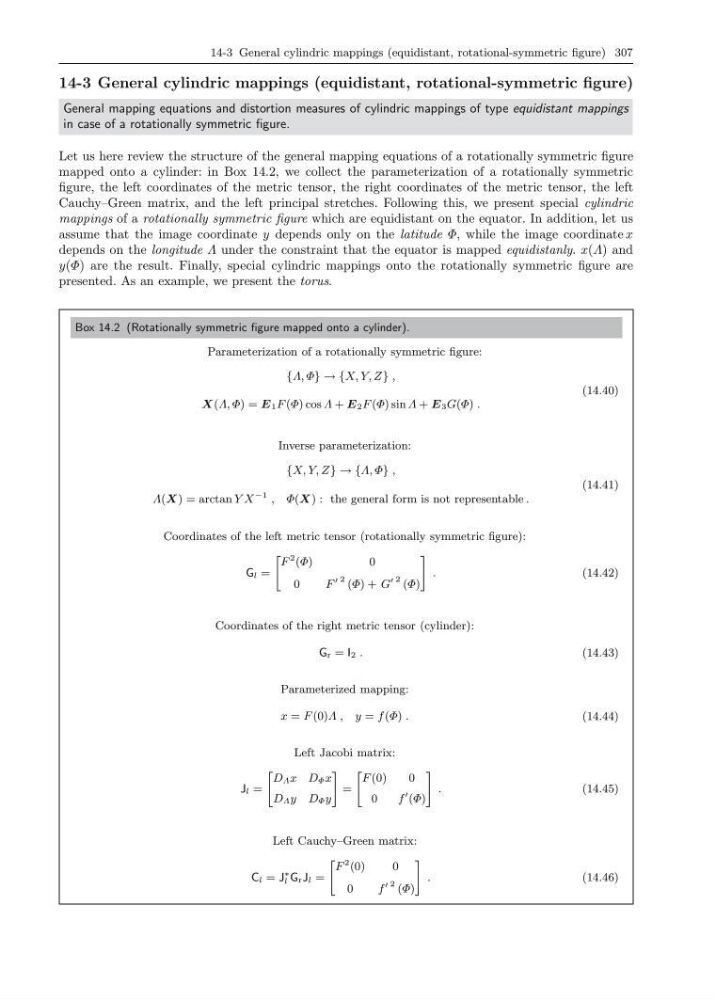
Let us here review the structure of the general mapping equations of a rotationally symmetric figure
mapped onto a cylinder: in Box 14.2, we collect the parameterization of a rotationally symmetric
figure, the left coordinates of the metric tensor, the right coordinates of the metric tensor, the left
Cauchy–Green matrix, and the left principal stretches. Following this, we present special cylindric
mappings of a rotationally symmetric figure which are equidistant on the equator. In addition, let us
assume that the image coordinate y depends only on the latitude Φ, while the image coordinate x
depends on the longitude Λ under the constraint that the equator is mapped equidistanly. x(Λ) and
y(Φ) are the result. Finally, special cylindric mappings onto the rotationally symmetric figure are
presented. As an example, we present the torus.
Box 14.2 (Rotationally symmetric figure mapped onto a cylinder).
Parameterization of a rotationally symmetric figure:
{Λ, Φ} → {X, Y, Z} ,
X(Λ, Φ) = E 1 F (Φ) cos Λ + E 2 F (Φ) sin Λ + E 3 G(Φ) .
(14.40)
Inverse parameterization:
{X, Y, Z} → {Λ, Φ} ,
Λ(X ) = arctan Y X
−1 , Φ(X ) : the general form is not representable .
(14.41)
Coordinates of the left metric tensor (rotationally symmetric figure):
G l =
"
F
2 (Φ)
0
0
F
2 (Φ) + G
2 (Φ)
#
.
(14.42)
Coordinates of the right metric tensor (cylinder):
G r = I 2 .
(14.43)
Parameterized mapping:
x = F (0)Λ , y = f (Φ) .
(14.44)
Left Jacobi matrix:
J l =
"
D Λ x D Φ x
D Λ y D Φ y
#
=
"
F (0)
0
0
f
(Φ)
#
.
(14.45)
Left Cauchy–Green matrix:
C l = J
∗
l G r J l =
"
F
2 (0)
0
0
f
2 (Φ)
#
.
(14.46)