

9-1 General mapping equations “ellipsoid-of-revolution to plane” 263
9-17 Deformation of the second kind
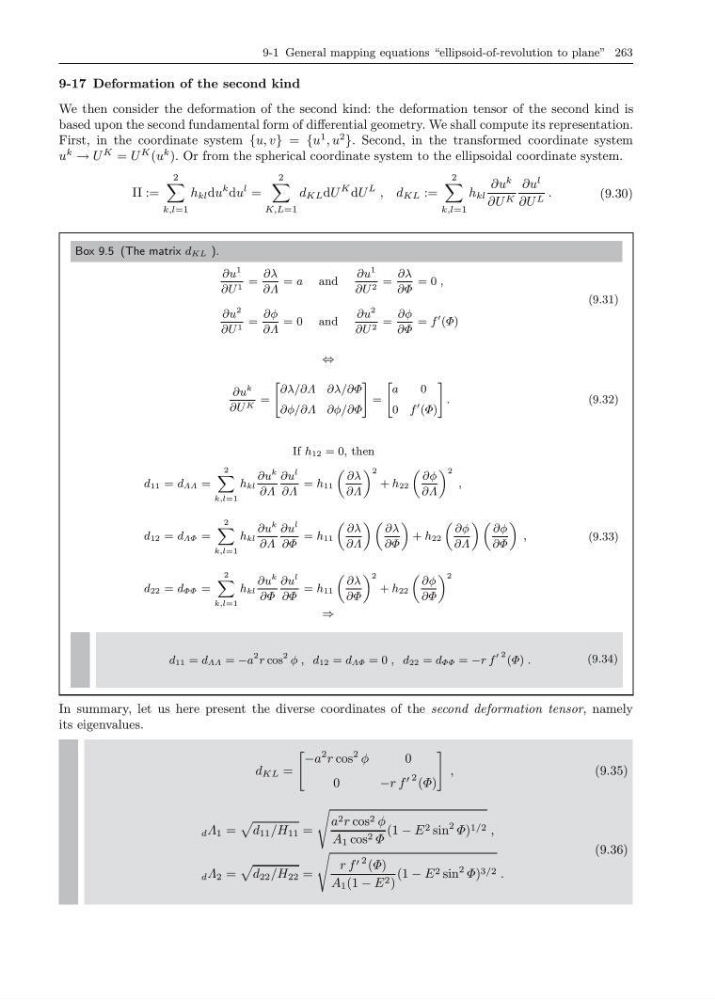
We then consider the deformation of the second kind: the deformation tensor of the second kind is
based upon the second fundamental form of differential geometry. We shall compute its representation.
First, in the coordinate system {u, v} = {u
1 , u
2
}. Second, in the transformed coordinate system
u
k
→ U
K = U
K (u
k ). Or from the spherical coordinate system to the ellipsoidal coordinate system.
II :=
2
k,l=1
h kl du
k du
l =
2
K,L=1
d KL dU
K dU
L , d KL :=
2
k,l=1
h kl
∂u
k
∂U K
∂u
l
∂U L .
(9.30)
Box 9.5 (The matrix d KL ).
∂u
1
∂U 1 =
∂λ
∂Λ
= a and
∂u
1
∂U 2 =
∂λ
∂Φ
= 0 ,
∂u
2
∂U 1 =
∂φ
∂Λ
= 0 and
∂u
2
∂U 2 =
∂φ
∂Φ
= f
(Φ)
(9.31)
⇔
∂u
k
∂U K =
"
∂λ/∂Λ ∂λ/∂Φ
∂φ/∂Λ ∂φ/∂Φ
#
=
"
a
0
0 f
(Φ)
#
.
(9.32)
If h 12 = 0, then
d 11 = d ΛΛ =
2
X
k,l=1
h kl
∂u
k
∂Λ
∂u
l
∂Λ
= h 11
„
∂λ
∂Λ
« 2
+ h 22
„
∂φ
∂Λ
« 2
,
d 12 = d ΛΦ =
2
X
k,l=1
h kl
∂u
k
∂Λ
∂u
l
∂Φ
= h 11
„
∂λ
∂Λ
« „
∂λ
∂Φ
«
+ h 22
„
∂φ
∂Λ
« „
∂φ
∂Φ
«
,
d 22 = d ΦΦ =
2
X
k,l=1
h kl
∂u
k
∂Φ
∂u
l
∂Φ
= h 11
„
∂λ
∂Φ
« 2
+ h 22
„
∂φ
∂Φ
« 2
(9.33)
⇒
d 11 = d ΛΛ = −a
2 r cos
2 φ , d 12 = d ΛΦ = 0 , d 22 = d ΦΦ = −r f
2 (Φ) .
(9.34)
In summary, let us here present the diverse coordinates of the second deformation tensor, namely
its eigenvalues.
d KL =
−a
2 r cos
2 φ
0
0
−r f
2 (Φ)
,
(9.35)
d Λ 1 =
d 11 /H 11 =
a 2 r cos 2 φ
A 1 cos 2 Φ
(1 − E 2 sin
2 Φ) 1/2 ,
d Λ 2 =
d 22 /H 22 =
r f 2 (Φ)
A 1 (1 − E 2 )
(1 − E 2 sin
2 Φ) 3/2 .
(9.36)