

6
1 From Riemann manifolds to Riemann manifolds
Example 1.3 (Cauchy-Green deformation tensor, f : E
2
A 1 ,A 1 ,A 2
→ S
2
r ).
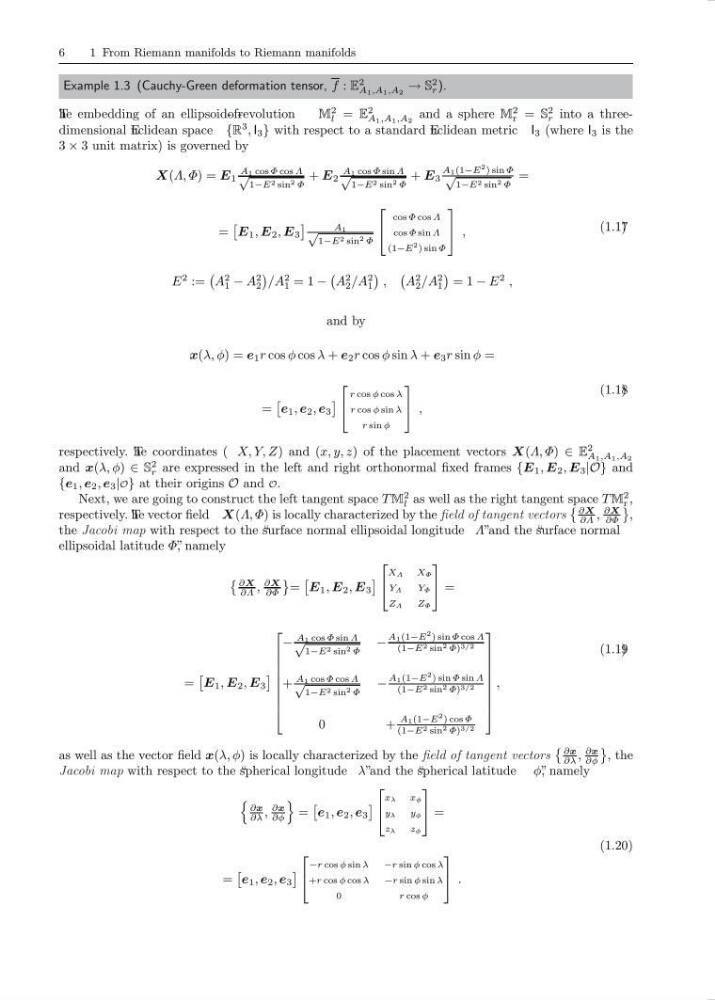
T he embedding of an ellipsoid- of- revolution
M
2
l = E
2
A 1 ,A 1 ,A 2
and a sphere M
2
r = S
2
r into a threedimensional E uclidean space {R
3 , I 3 } with respect to a standard E uclidean metric I 3 (where I 3 is the
3 × 3 unit matrix) is governed by
X(Λ, Φ) = E 1
A 1 cos Φ cos Λ
√
1−E 2 sin 2 Φ
+ E 2
A 1 cos Φ sin Λ
√
1−E 2 sin 2 Φ
+ E 3
A 1 (1−E
2 ) sin Φ
√
1−E 2 sin 2 Φ
=
=
E 1 , E 2 , E 3
A 1
√
1−E 2 sin 2 Φ
⎡
⎣
cos Φ cos Λ
cos Φ sin Λ
(1−E
2 ) sin Φ
⎤
⎦ ,
E
2 :=
A
2
1 − A
2
2
/A
2
1 = 1 −
A
2
2 /A
2
1
,
A
2
2 /A
2
1
= 1 − E
2 ,
(1.17 )
and by
x(λ, φ) = e 1 r cos φ cos λ + e 2 r cos φ sin λ + e 3 r sin φ =
=
e 1 , e 2 , e 3
⎡
⎣
r cos φ cos λ
r cos φ sin λ
r sin φ
⎤
⎦ ,
(1.18 )
respectively. T he coordinates ( X, Y, Z) and (x, y, z) of the placement vectors X(Λ, Φ) ∈ E
2
A 1 ,A 1 ,A 2
and x(λ, φ) ∈ S
2
r are expressed in the left and right orthonormal fixed frames {E 1 , E 2 , E 3 |O} and
{e 1 , e 2 , e 3 |O} at their origins O and O.
Next, we are going to construct the left tangent space T M
2
l as well as the right tangent space T M
2
r ,
respectively. T he vector field X(Λ, Φ) is locally characterized by the field of tangent vectors
∂X
∂Λ ,
∂X
∂Φ
,
the Jacobi map with respect to the “ surface normal ellipsoidal longitude Λ”and the “ surface normal
ellipsoidal latitude Φ” , namely
∂X
∂Λ ,
∂X
∂Φ
=
E 1 , E 2 , E 3
⎡
⎣
X Λ
X Φ
Y Λ
Y Φ
Z Λ
Z Φ
⎤
⎦ =
=
E 1 , E 2 , E 3
⎡
⎢
⎢
⎢
⎢
⎢
⎢
⎢
⎣
−
A 1 cos Φ sin Λ
√
1−E 2 sin 2 Φ
−
A 1 (1−E
2 ) sin Φ cos Λ
(1−E 2 sin 2 Φ) 3/2
+
A 1 cos Φ cos Λ
√
1−E 2 sin 2 Φ
−
A 1 (1−E
2 ) sin Φ sin Λ
(1−E 2 sin 2 Φ) 3/2
0
+
A 1 (1−E
2 ) cos Φ
(1−E 2 sin 2 Φ) 3/2
⎤
⎥
⎥
⎥
⎥
⎥
⎥
⎥
⎦
,
(1.19 )
as well as the vector field x(λ, φ) is locally characterized by the field of tangent vectors
∂x
∂λ ,
∂x
∂φ
, the
Jacobi map with respect to the “ spherical longitude λ”and the “ spherical latitude φ” , namely
∂x
∂λ ,
∂x
∂φ
=
e 1 , e 2 , e 3
⎡
⎣
x λ
x φ
y λ
y φ
z λ
z φ
⎤
⎦ =
=
e 1 , e 2 , e 3
⎡
⎣
−r cos φ sin λ
−r sin φ cos λ
+r cos φ cos λ
−r sin φ sin λ
0
r cos φ
⎤
⎦ .
(1.20)