

2-4 The equivalence theorem for equiareal mappings 107
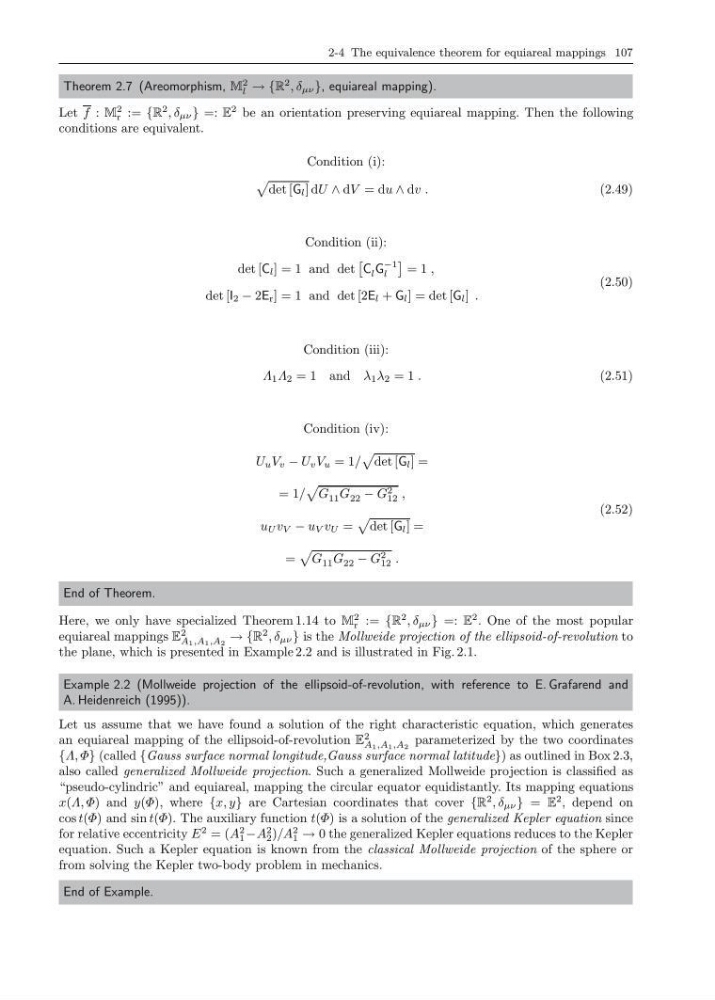
Theorem 2.7 (Areomorphism, M
2
l → {R
2 , δ µν }, equiareal mapping).
Let f : M
2
r := {R
2 , δ µν } =: E
2 be an orientation preserving equiareal mapping. Then the following
conditions are equivalent.
Condition (i):
det [G l ] dU ∧ dV = du ∧ dv .
(2.49)
Condition (ii):
det [C l ] = 1 and det
C l G
−1
l
= 1 ,
det [I 2 − 2E r ] = 1 and det [2E l + G l ] = det [G l ] .
(2.50)
Condition (iii):
Λ 1 Λ 2 = 1 and λ 1 λ 2 = 1 .
(2.51)
Condition (iv):
U u V v − U v V u = 1/
det [G l ] =
= 1/
G 11 G 22 − G 2
12 ,
u U v V − u V v U =
det [G l ] =
=
G 11 G 22 − G 2
12 .
(2.52)
End of Theorem.
Here, we only have specialized Theorem 1.14 to M
2
r := {R
2 , δ µν } =: E
2 . One of the most popular
equiareal mappings E
2
A 1 ,A 1 ,A 2
→ {R
2 , δ µν } is the Mollweide projection of the ellipsoid-of-revolution to
the plane, which is presented in Example 2.2 and is illustrated in Fig. 2.1.
Example 2.2 (Mollweide projection of the ellipsoid-of-revolution, with reference to E. Grafarend and
A. Heidenreich (1995)).
Let us assume that we have found a solution of the right characteristic equation, which generates
an equiareal mapping of the ellipsoid-of-revolution E
2
A 1 ,A 1 ,A 2
parameterized by the two coordinates
{Λ, Φ} (called {Gauss surface normal longitude,Gauss surface normal latitude}) as outlined in Box 2.3,
also called generalized Mollweide projection. Such a generalized Mollweide projection is classified as
“pseudo-cylindric” and equiareal, mapping the circular equator equidistantly. Its mapping equations
x(Λ, Φ) and y(Φ), where {x, y} are Cartesian coordinates that cover {R
2 , δ µν } = E
2 , depend on
cos t(Φ) and sin t(Φ). The auxiliary function t(Φ) is a solution of the generalized Kepler equation since
for relative eccentricity E
2 = (A
2
1 −A
2
2 )/A
2
1 → 0 the generalized Kepler equations reduces to the Kepler
equation. Such a Kepler equation is known from the classical Mollweide projection of the sphere or
from solving the Kepler two-body problem in mechanics.
End of Example.