

302
7 Lagrangian and Hamiltonian Mechanics
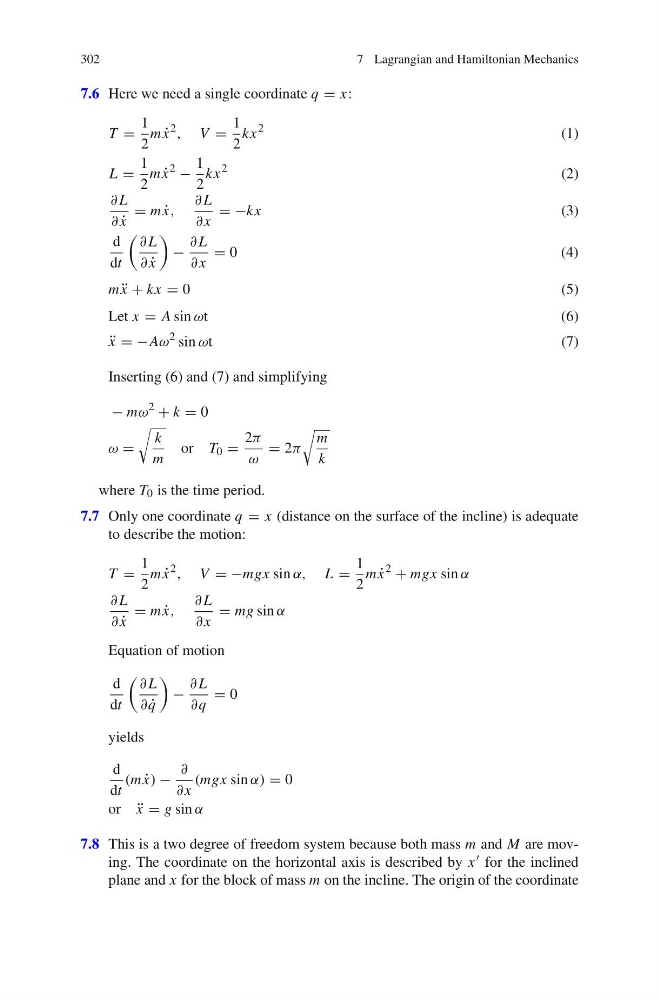
7.6 Here we need a single coordinate q = x:
T =
1
2
m ˙
x
2
, V =
1
2
kx
2
(1)
L =
1
2
m ˙
x
2
−
1
2
kx
2
(2)
∂ L
∂ ˙
x
= m ˙
x,
∂ L
∂ x
= −kx
(3)
d
dt
∂ L
∂ ˙
x
−
∂ L
∂ x
= 0
( 4 )
m ¨
x + kx = 0
( 5 )
Let x = A sin ωt
( 6 )
¨
x = −Aω
2 sin ωt
( 7 )
Inserting (6) and (7) and simplifying
− mω
2
+ k = 0
ω =
k
m
or T 0 =
2π
ω
= 2π
m
k
where T 0 is the time period.
7.7 Only one coordinate q = x (distance on the surface of the incline) is adequate
to describe the motion:
T =
1
2
m ˙
x
2
, V = −mgx sin α, L =
1
2
m ˙
x
2
+ mgx sin α
∂ L
∂ ˙
x
= m ˙
x,
∂ L
∂ x
= mg sin α
Equation of motion
d
dt
∂ L
∂ ˙
q
−
∂ L
∂q
= 0
yields
d
dt
(m ˙
x) −
∂
∂ x
(mgx sin α) = 0
or ¨
x = g sin α
7.8 This is a two degree of freedom system because both mass m and M are moving. The coordinate on the horizontal axis is described by x for the inclined
plane and x for the block of mass m on the incline. The origin of the coordinate