

270
6 Oscillations
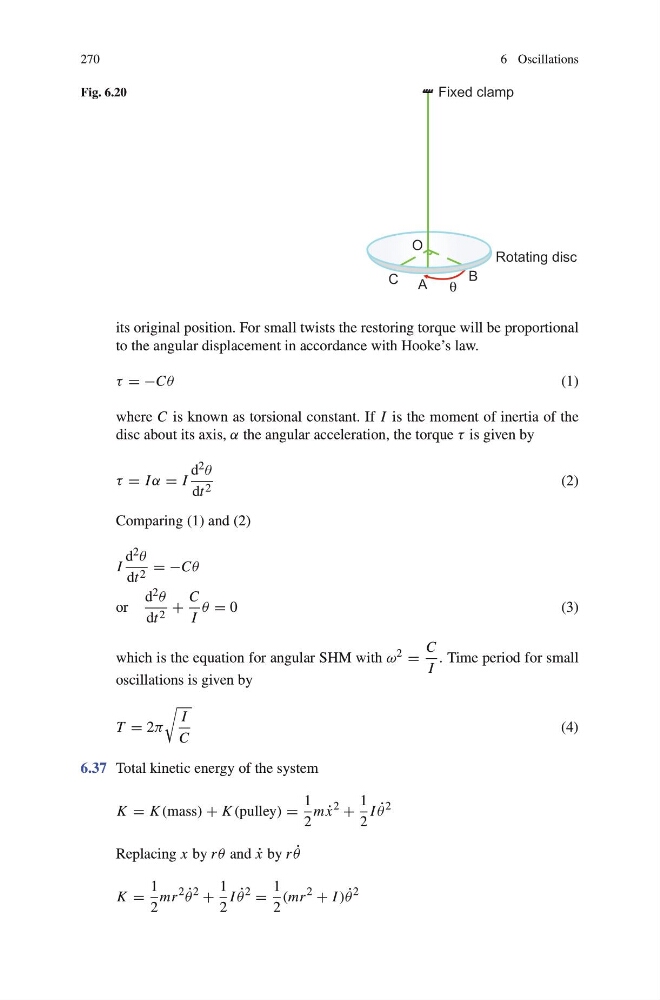
Fig. 6.20
its original position. For small twists the restoring torque will be proportional
to the angular displacement in accordance with Hooke’s law.
τ = −Cθ
(1)
where C is known as torsional constant. If I is the moment of inertia of the
disc about its axis, α the angular acceleration, the torque τ is given by
τ = I α = I
d 2 θ
dt 2
(2)
Comparing (1) and (2)
I
d 2 θ
dt 2 = −Cθ
or
d 2 θ
dt 2 +
C
I
θ = 0
( 3 )
which is the equation for angular SHM with ω 2 =
C
I
. Time period for small
oscillations is given by
T = 2π
I
C
(4)
6.37 Total kinetic energy of the system
K = K (mass) + K (pulley) =
1
2
m ˙
x
2
+
1
2
I ˙
θ
2
Replacing x by r θ and ˙
x by r ˙
θ
K =
1
2
mr
2 ˙
θ
2
+
1
2
I ˙
θ
2
=
1
2
(mr
2
+ I ) ˙
θ
2