

168
4 Rotational Dynamics
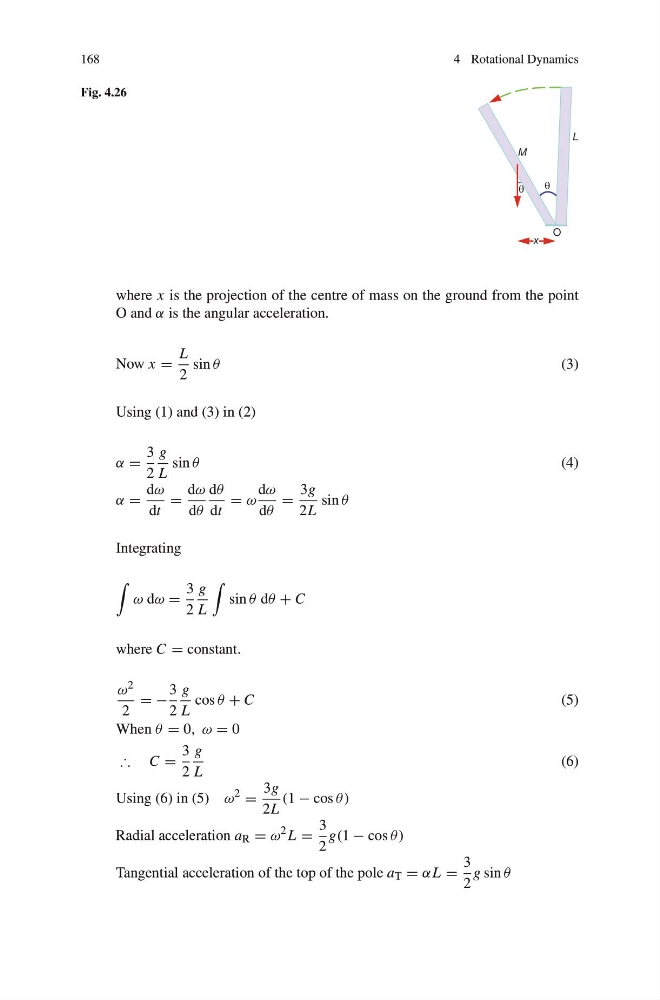
Fig. 4.26
where x is the projection of the centre of mass on the ground from the point
O and α is the angular acceleration.
Now x =
L
2
sin θ
(3)
Using (1) and (3) in (2)
α =
3
2
g
L
sin θ
(4)
α =
dω
dt
=
dω
dθ
dθ
dt
= ω
dω
dθ
=
3g
2L
sin θ
Integrating
ω dω =
3
2
g
L
sin θ dθ + C
where C = constant.
ω 2
2
= −
3
2
g
L
cos θ + C
(5)
When θ = 0, ω = 0
∴ C =
3
2
g
L
(6)
Using (6) in (5) ω
2
=
3g
2L
(1 − cos θ)
Radial acceleration a R = ω
2 L =
3
2
g(1 − cos θ)
Tangential acceleration of the top of the pole a T = αL =
3
2
g sin θ