

2.5 Particle Velocimetry Measurements
71
filter. The circular-shaped filter has been added to the algorithm to improve the
particle tracking of the circular-shaped glass particles. Then the locations of the
pebbles are identified by the Dynamic-Threshold Binarization (DTB) method. The
threshold level is dynamically determined particle by particle and frame by frame.
The DTB uses the threshold level on the basis of the mean gray degree of each particle
image, which is advantageous over the Single-Threshold Binarization (STB) method
using the fixed single threshold level to detect the particle.
Moreover, the synthetic particle images published by the Visualization Society
of Japan (VSJ) [18] are used to check the DTB method. The VSJ supplies particle
image sets for evaluating various preprocessing methods, which have been used by
lots of researchers [12, 19, 20]. The VSJ#302 set (Fig. 2.34) is used here, which
includes 147 frames with about 1,000 particles in each frame. An error analysis
related to the quantified measurement reliability consists of the particle location
error and the RMS error obtained from more than 100,000 measurable particles. The
particle-pairing effectiveness is examined through the total measurement Φ y , which
is defined as the ratio of the measured numbers (N m ) to the total number of particles
(N a ), and the reliability Φ r , which is defined as the ratio of the correctly identified
particles N c (within 1-pixel error) to the total number of measured particles N m . The
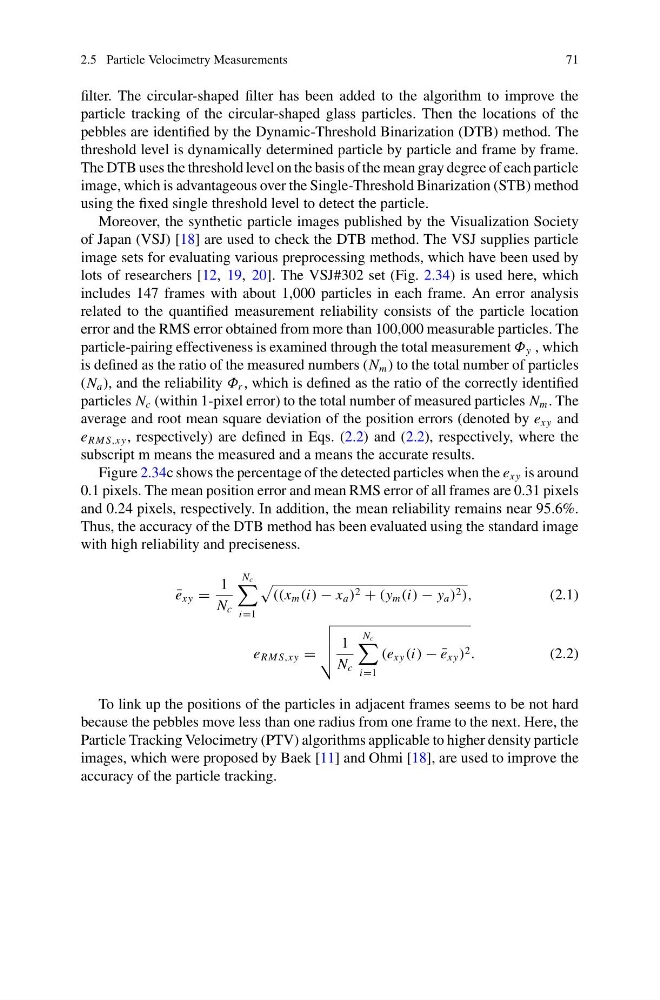
average and root mean square deviation of the position errors (denoted by e xy and
e RM S,xy , respectively) are defined in Eqs. (2.2) and (2.2), respectively, where the
subscript m means the measured and a means the accurate results.
Figure 2.34c shows the percentage of the detected particles when the e xy is around
0.1 pixels. The mean position error and mean RMS error of all frames are 0.31 pixels
and 0.24 pixels, respectively. In addition, the mean reliability remains near 95.6%.
Thus, the accuracy of the DTB method has been evaluated using the standard image
with high reliability and preciseness.
¯
e xy =
1
N c
N c
i=1
((x m (i) − x a ) 2 + (y m (i) − y a ) 2 ),
(2.1)
e RM S,xy =
1
N c
N c
i=1
(e xy (i) − ¯
e xy ) 2 .
(2.2)
To link up the positions of the particles in adjacent frames seems to be not hard
because the pebbles move less than one radius from one frame to the next. Here, the
Particle Tracking Velocimetry (PTV) algorithms applicable to higher density particle
images, which were proposed by Baek [11] and Ohmi [18], are used to improve the
accuracy of the particle tracking.