

98
2 Experiments in Pebble Flows
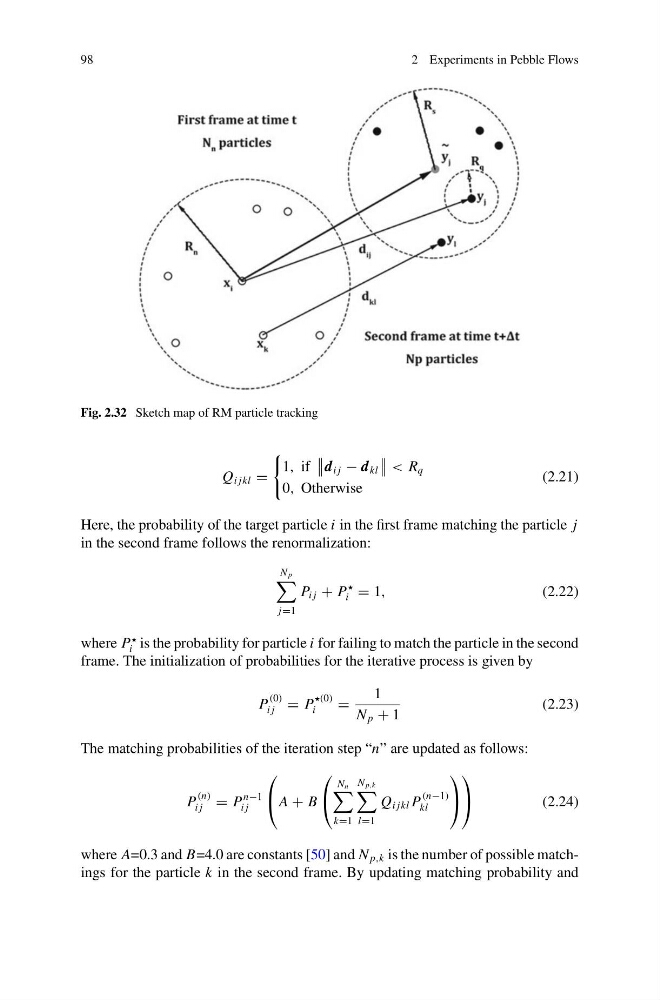
Fig. 2.32 Sketch map of RM particle tracking
Q i jkl =
1, if
d i j − d kl
< R q
0, Otherwise
(2.21)
Here, the probability of the target particle i in the first frame matching the particle j
in the second frame follows the renormalization:
N p
j=1
P i j + P
i = 1,
(2.22)
where P
i is the probability for particle i for failing to match the particle in the second
frame. The initialization of probabilities for the iterative process is given by
P
(0)
i j = P
(0)
i
=
1
N p + 1
(2.23)
The matching probabilities of the iteration step “n” are updated as follows:
P
(n)
i j = P
n−1
i j
⎛
⎝ A + B
⎛
⎝
N n
k=1
N p,k
l=1
Q i jkl P
(n−1)
kl
⎞
⎠
⎞
⎠
(2.24)
where A=0.3 and B=4.0 are constants [50] and N p,k is the number of possible matchings for the particle k in the second frame. By updating matching probability and