

412
11 Nonlinear Dynamics of Circuits with Mem-Elements
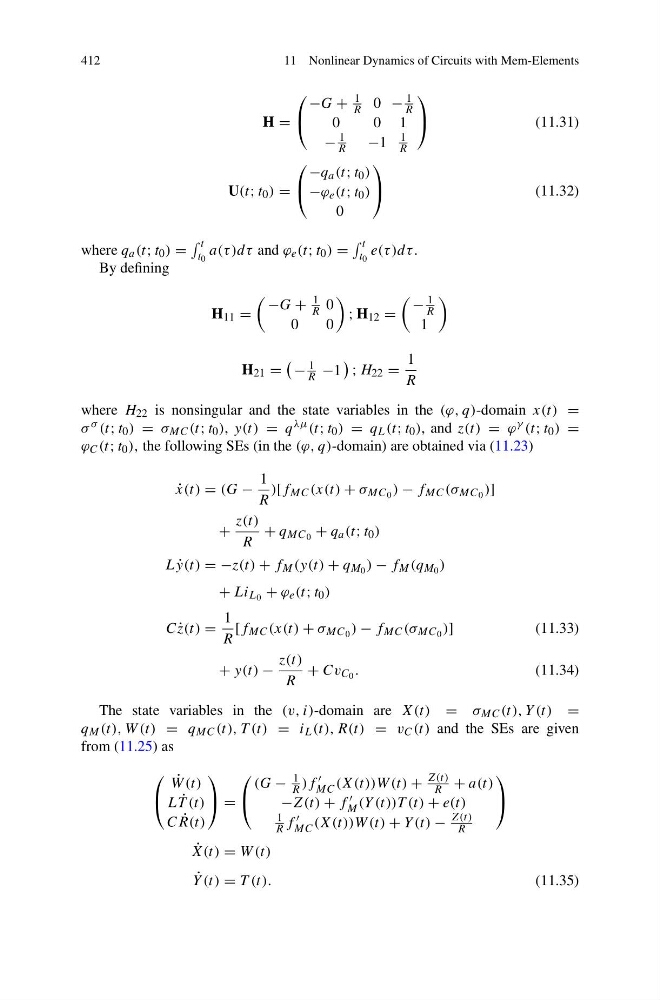
H =
⎛
⎝
−G +
1
R 0 −
1
R
0
0 1
−
1
R
−1
1
R
⎞
⎠
(11.31)
U(t; t 0 ) =
⎛
⎝
−q a (t; t 0 )
−ϕ e (t; t 0 )
0
⎞
⎠
(11.32)
where q a (t; t 0 ) =
t
t 0
a(τ )dτ and ϕ e (t; t 0 ) =
t
t 0
e(τ )dτ .
By defining
H 11 =
−G +
1
R 0
0
0
; H 12 =
−
1
R
1
H 21 =
−
1
R −1
; H 22 =
1
R
where H 22 is nonsingular and the state variables in the (ϕ, q)-domain x(t) =
σ σ (t; t 0 ) = σ MC (t; t 0 ), y(t) = q λμ (t; t 0 ) = q L (t; t 0 ), and z(t) = ϕ γ (t; t 0 ) =
ϕ C (t; t 0 ), the following SEs (in the (ϕ, q)-domain) are obtained via (11.23)
˙
x(t) = (G −
1
R
)[f MC (x(t) + σ MC 0 ) − f MC (σ MC 0 )]
+
z(t)
R
+ q MC 0 + q a (t; t 0 )
L ˙
y(t) = −z(t) + f M (y(t) + q M 0 ) − f M (q M 0 )
+ Li L 0 + ϕ e (t; t 0 )
C ˙
z(t) =
1
R
[f MC (x(t) + σ MC 0 ) − f MC (σ MC 0 )]
(11.33)
+ y(t) −
z(t)
R
+ Cv C 0 .
(11.34)
The state variables in the (v, i)-domain are X(t) = σ MC (t), Y (t) =
q M (t), W (t) = q MC (t), T (t) = i L (t), R(t) = v C (t) and the SEs are given
from (11.25) as
⎛
⎝
˙
W (t)
L ˙
T (t)
C ˙
R(t)
⎞
⎠ =
⎛
⎝
(G −
1
R )f
MC (X(t))W (t) +
Z(t)
R + a(t)
−Z(t) + f
M (Y (t))T (t) + e(t)
1
R f
MC (X(t))W (t) + Y (t) −
Z(t)
R
⎞
⎠
˙
X(t) = W (t)
˙
Y (t) = T (t).
(11.35)