

7.3 Structure of Memristor Network and Differential Algebraic Equation. . .
275
and charge in the memristor (i.e., the voltage and current momenta), respectively.
Moreover, each charge-controlled memristor has a CR of the type ϕ(t) = h(q(t)).
We wish to analyze the nonlinear dynamics and bifurcations in a memristor
network N ∈ LM for t ≥ t 0 , where t 0 is a given finite time instant. For any
two-terminal circuit element in N, in addition to the voltage v(t), current i(t), flux
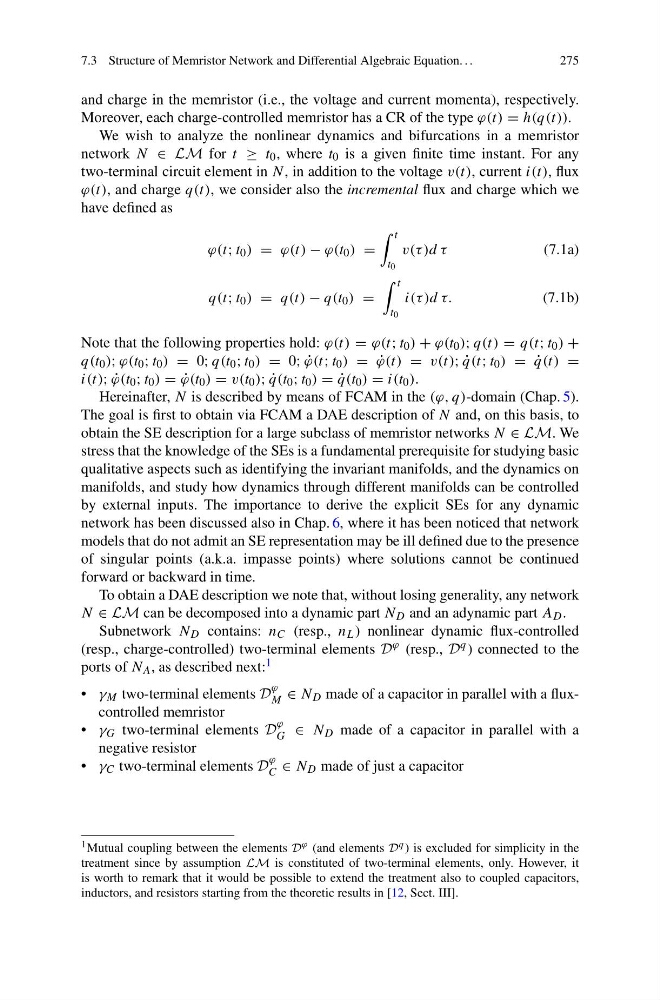
ϕ(t), and charge q(t), we consider also the incremental flux and charge which we
have defined as
ϕ(t; t 0 ) = ϕ(t) − ϕ(t 0 ) =
t
t 0
v(τ )d τ
(7.1a)
q(t; t 0 ) = q(t) − q(t 0 ) =
t
t 0
i(τ )d τ.
(7.1b)
Note that the following properties hold: ϕ(t) = ϕ(t; t 0 ) + ϕ(t 0 ); q(t) = q(t; t 0 ) +
q(t 0 ); ϕ(t 0 ; t 0 ) = 0; q(t 0 ; t 0 ) = 0; ˙
ϕ(t; t 0 ) = ˙
ϕ(t) = v(t); ˙
q(t; t 0 ) = ˙
q(t) =
i(t); ˙
ϕ(t 0 ; t 0 ) = ˙
ϕ(t 0 ) = v(t 0 ); ˙
q(t 0 ; t 0 ) = ˙
q(t 0 ) = i(t 0 ).
Hereinafter, N is described by means of FCAM in the (ϕ, q)-domain (Chap. 5).
The goal is first to obtain via FCAM a DAE description of N and, on this basis, to
obtain the SE description for a large subclass of memristor networks N ∈ LM. We
stress that the knowledge of the SEs is a fundamental prerequisite for studying basic
qualitative aspects such as identifying the invariant manifolds, and the dynamics on
manifolds, and study how dynamics through different manifolds can be controlled
by external inputs. The importance to derive the explicit SEs for any dynamic
network has been discussed also in Chap. 6, where it has been noticed that network
models that do not admit an SE representation may be ill defined due to the presence
of singular points (a.k.a. impasse points) where solutions cannot be continued
forward or backward in time.
To obtain a DAE description we note that, without losing generality, any network
N ∈ LM can be decomposed into a dynamic part N D and an adynamic part A D .
Subnetwork N D contains: n C (resp., n L ) nonlinear dynamic flux-controlled
(resp., charge-controlled) two-terminal elements D ϕ (resp., D q ) connected to the
ports of N A , as described next: 1
• γ M two-terminal elements D
ϕ
M ∈ N D made of a capacitor in parallel with a fluxcontrolled memristor
• γ G two-terminal elements D
ϕ
G ∈ N D made of a capacitor in parallel with a
negative resistor
• γ C two-terminal elements D
ϕ
C ∈ N D made of just a capacitor
1 Mutual coupling between the elements D ϕ (and elements D q ) is excluded for simplicity in the
treatment since by assumption LM is constituted of two-terminal elements, only. However, it
is worth to remark that it would be possible to extend the treatment also to coupled capacitors,
inductors, and resistors starting from the theoretic results in [12, Sect. III].