

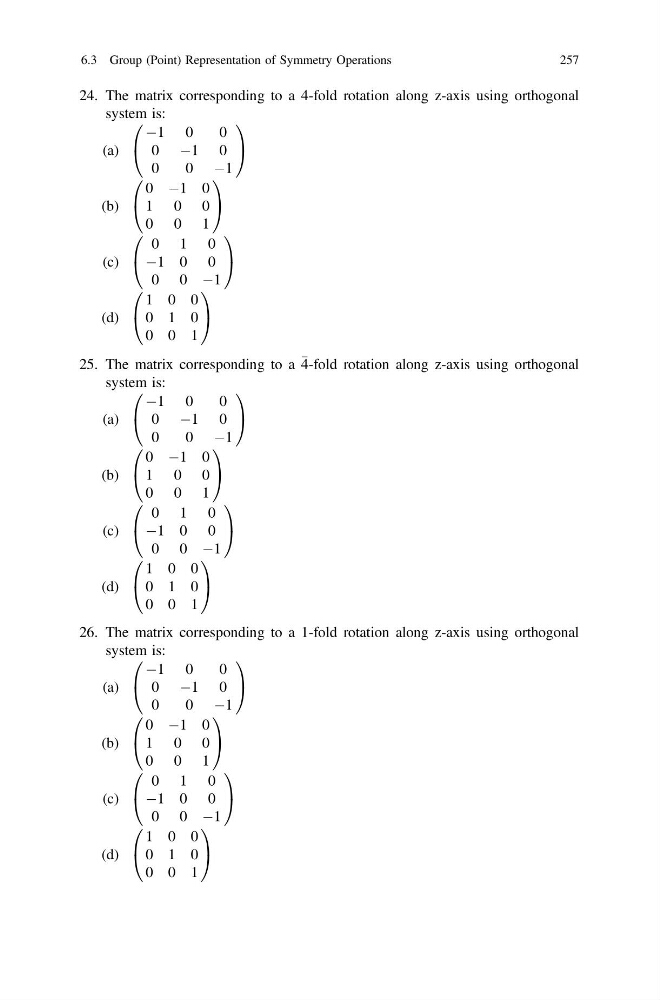
24. The matrix corresponding to a 4-fold rotation along z-axis using orthogonal
system is:
(a)
À1 0
0
0 À1 0
0
0 À1
0
@
1
A
(b)
0 À1 0
1 0 0
0 0 1
0
@
1
A
(c)
0 1 0
À1 0 0
0 0 À1
0
@
1
A
(d)
1 0 0
0 1 0
0 0 1
0
@
1
A
25. The matrix corresponding to a 4-fold rotation along z-axis using orthogonal
system is:
(a)
À1 0
0
0 À1 0
0
0 À1
0
@
1
A
(b)
0 À1 0
1 0 0
0 0 1
0
@
1
A
(c)
0 1 0
À1 0 0
0 0 À1
0
@
1
A
(d)
1 0 0
0 1 0
0 0 1
0
@
1
A
26. The matrix corresponding to a 1-fold rotation along z-axis using orthogonal
system is:
(a)
À1 0
0
0 À1 0
0
0 À1
0
@
1
A
(b)
0 À1 0
1 0 0
0 0 1
0
@
1
A
(c)
0 1 0
À1 0 0
0 0 À1
0
@
1
A
(d)
1 0 0
0 1 0
0 0 1
0
@
1
A
6.3 Group (Point) Representation of Symmetry Operations
257
system is:
(a)
À1 0
0
0 À1 0
0
0 À1
0
@
1
A
(b)
0 À1 0
1 0 0
0 0 1
0
@
1
A
(c)
0 1 0
À1 0 0
0 0 À1
0
@
1
A
(d)
1 0 0
0 1 0
0 0 1
0
@
1
A
25. The matrix corresponding to a 4-fold rotation along z-axis using orthogonal
system is:
(a)
À1 0
0
0 À1 0
0
0 À1
0
@
1
A
(b)
0 À1 0
1 0 0
0 0 1
0
@
1
A
(c)
0 1 0
À1 0 0
0 0 À1
0
@
1
A
(d)
1 0 0
0 1 0
0 0 1
0
@
1
A
26. The matrix corresponding to a 1-fold rotation along z-axis using orthogonal
system is:
(a)
À1 0
0
0 À1 0
0
0 À1
0
@
1
A
(b)
0 À1 0
1 0 0
0 0 1
0
@
1
A
(c)
0 1 0
À1 0 0
0 0 À1
0
@
1
A
(d)
1 0 0
0 1 0
0 0 1
0
@
1
A
6.3 Group (Point) Representation of Symmetry Operations
257