

) A
À1 A ¼ AA
À1
¼ E:
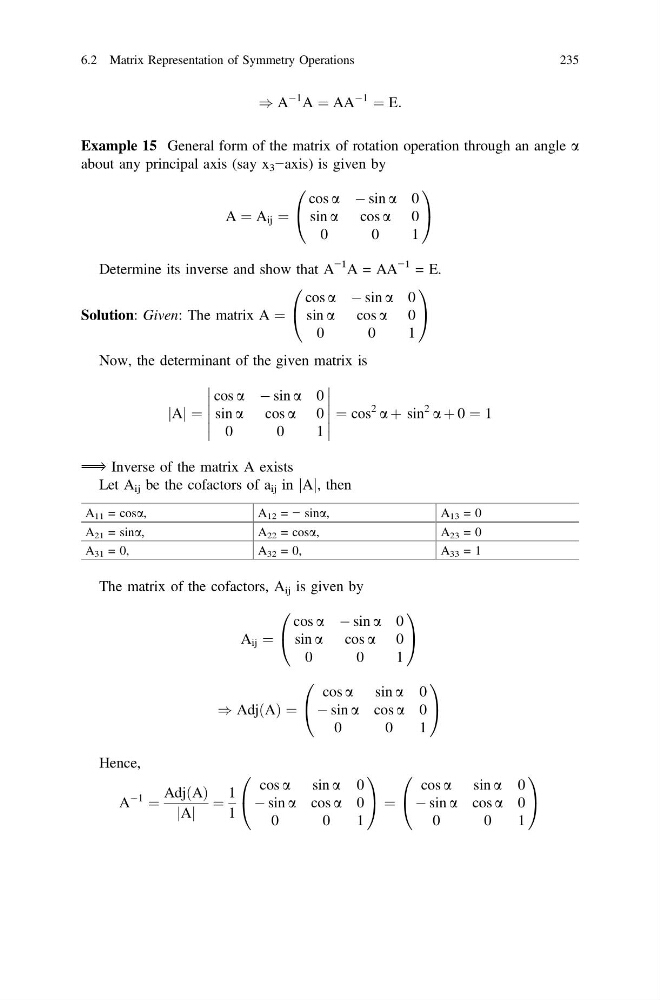
Example 15 General form of the matrix of rotation operation through an angle a
about any principal axis (say x 3 −axis) is given by
A ¼ A ij ¼
cos a À sin a 0
sin a cos a 0
0
0
1
0
@
1
A
Determine its inverse and show that A
−1 A = AA
−1 = E.
Solution: Given: The matrix A ¼
cos a À sin a 0
sin a cos a 0
0
0
1
0
@
1
A
Now, the determinant of the given matrix is
A
j j ¼
cos a À sin a 0
sin a cos a 0
0
0
1
¼ cos
2
a þ sin
2
a þ 0 ¼ 1
⟹ Inverse of the matrix A exists
Let A ij be the cofactors of a ij in A
j j, then
A 11 = cosa,
A 12 = − sina,
A 13 = 0
A 21 = sina,
A 22 = cosa,
A 23 = 0
A 31 = 0,
A 32 = 0,
A 33 = 1
The matrix of the cofactors, A ij is given by
A ij ¼
cos a À sin a 0
sin a cos a 0
0
0
1
0
@
1
A
) AdjðAÞ ¼
cos a sin a 0
À sin a cos a 0
0
0
1
0
@
1
A
Hence,
A
À1
¼
AdjðAÞ
A
j j
¼
1
1
cos a sin a 0
À sin a cos a 0
0
0
1
0
@
1
A ¼
cos a sin a 0
À sin a cos a 0
0
0
1
0
@
1
A
6.2 Matrix Representation of Symmetry Operations
235