

230
7 Guidance, Navigation and Control Technology …
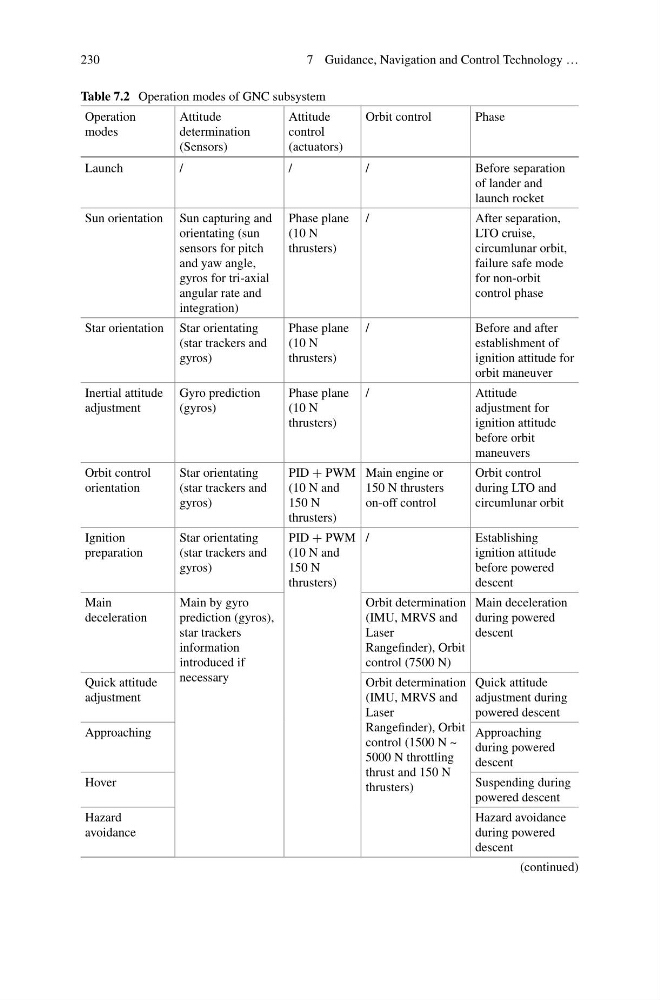
Table 7.2 Operation modes of GNC subsystem
Operation
modes
Attitude
determination
(Sensors)
Attitude
control
(actuators)
Orbit control
Phase
Launch
/
/
/
Before separation
of lander and
launch rocket
Sun orientation Sun capturing and
orientating (sun
sensors for pitch
and yaw angle,
gyros for tri-axial
angular rate and
integration)
Phase plane
(10 N
thrusters)
/
After separation,
LTO cruise,
circumlunar orbit,
failure safe mode
for non-orbit
control phase
Star orientation Star orientating
(star trackers and
gyros)
Phase plane
(10 N
thrusters)
/
Before and after
establishment of
ignition attitude for
orbit maneuver
Inertial attitude
adjustment
Gyro prediction
(gyros)
Phase plane
(10 N
thrusters)
/
Attitude
adjustment for
ignition attitude
before orbit
maneuvers
Orbit control
orientation
Star orientating
(star trackers and
gyros)
PID + PWM
(10 N and
150 N
thrusters)
Main engine or
150 N thrusters
on-off control
Orbit control
during LTO and
circumlunar orbit
Ignition
preparation
Star orientating
(star trackers and
gyros)
PID + PWM
(10 N and
150 N
thrusters)
/
Establishing
ignition attitude
before powered
descent
Main
deceleration
Main by gyro
prediction (gyros),
star trackers
information
introduced if
necessary
Orbit determination
(IMU, MRVS and
Laser
Rangefinder), Orbit
control (7500 N)
Main deceleration
during powered
descent
Quick attitude
adjustment
Orbit determination
(IMU, MRVS and
Laser
Rangefinder), Orbit
control (1500 N ~
5000 N throttling
thrust and 150 N
thrusters)
Quick attitude
adjustment during
powered descent
Approaching
Approaching
during powered
descent
Hover
Suspending during
powered descent
Hazard
avoidance
Hazard avoidance
during powered
descent
(continued)