

4.4 Mechanism Design and Verification of Lunar Lander
143
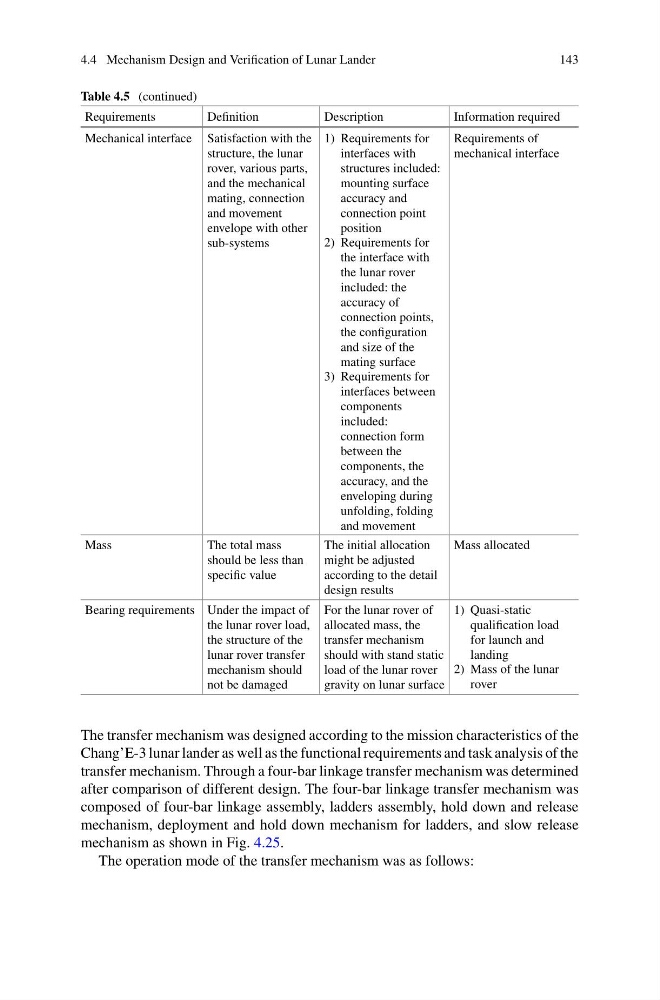
Table 4.5 (continued)
Requirements
Definition
Description
Information required
Mechanical interface Satisfaction with the
structure, the lunar
rover, various parts,
and the mechanical
mating, connection
and movement
envelope with other
sub-systems
1) Requirements for
interfaces with
structures included:
mounting surface
accuracy and
connection point
position
2) Requirements for
the interface with
the lunar rover
included: the
accuracy of
connection points,
the configuration
and size of the
mating surface
3) Requirements for
interfaces between
components
included:
connection form
between the
components, the
accuracy, and the
enveloping during
unfolding, folding
and movement
Requirements of
mechanical interface
Mass
The total mass
should be less than
specific value
The initial allocation
might be adjusted
according to the detail
design results
Mass allocated
Bearing requirements Under the impact of
the lunar rover load,
the structure of the
lunar rover transfer
mechanism should
not be damaged
For the lunar rover of
allocated mass, the
transfer mechanism
should with stand static
load of the lunar rover
gravity on lunar surface
1) Quasi-static
qualification load
for launch and
landing
2) Mass of the lunar
rover
The transfer mechanism was designed according to the mission characteristics of the
Chang’E-3 lunar lander as well as the functional requirements and task analysis of the
transfer mechanism. Through a four-bar linkage transfer mechanism was determined
after comparison of different design. The four-bar linkage transfer mechanism was
composed of four-bar linkage assembly, ladders assembly, hold down and release
mechanism, deployment and hold down mechanism for ladders, and slow release
mechanism as shown in Fig. 4.25.
The operation mode of the transfer mechanism was as follows: