

458
W. Wu et al.
P i = v u × t i
=
(x f − y s ) 2 + (y f − y s ) 2
v u
+ dT i
· v u
=
(x f − y s ) 2 + (y f − y s ) 2 + v u · dT i
(40.5)
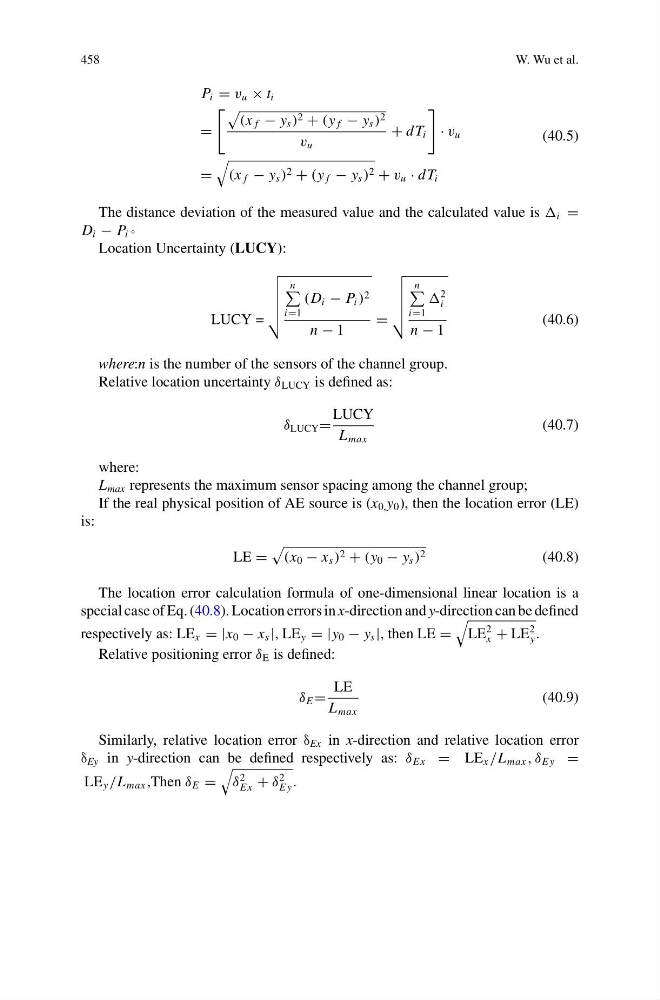
The distance deviation of the measured value and the calculated value is i =
D i − P i 。
Location Uncertainty (LUCY):
LUCY =
n
i=1
(D i − P i ) 2
n − 1
=
n
i=1
2
i
n − 1
(40.6)
where:n is the number of the sensors of the channel group.
Relative location uncertainty δ LUCY is defined as:
δ LUCY =
LUCY
L max
(40.7)
where:
L max represents the maximum sensor spacing among the channel group;
If the real physical position of AE source is (x 0, y 0 ), then the location error (LE)
is:
LE =
(x 0 − x s ) 2 + (y 0 − y s ) 2
(40.8)
The location error calculation formula of one-dimensional linear location is a
special case of Eq. (40.8). Location errors in x-direction and y-direction can be defined
respectively as: LE x = |x 0 − x s |, LE y = |y 0 − y s |, then LE =
LE
2
x + LE
2
y .
Relative positioning error δ E is defined:
δ E =
LE
L max
(40.9)
Similarly, relative location error δ Ex in x-direction and relative location error
δ Ey in y-direction can be defined respectively as: δ E x = LE x /L max , δ Ey =
LE y /L max ,Then δ E =
δ
2
E x + δ
2
Ey .