

6.3 Probability Density that Extremizes Information
161
is a measure that only involves the off-diagonal elements of δ ¯
O. Note that the
contribution from the eigenvalues is independent of the contribution from the
eigenvectors δδ δO . An example for the case of a 2×2 matrix is given below.
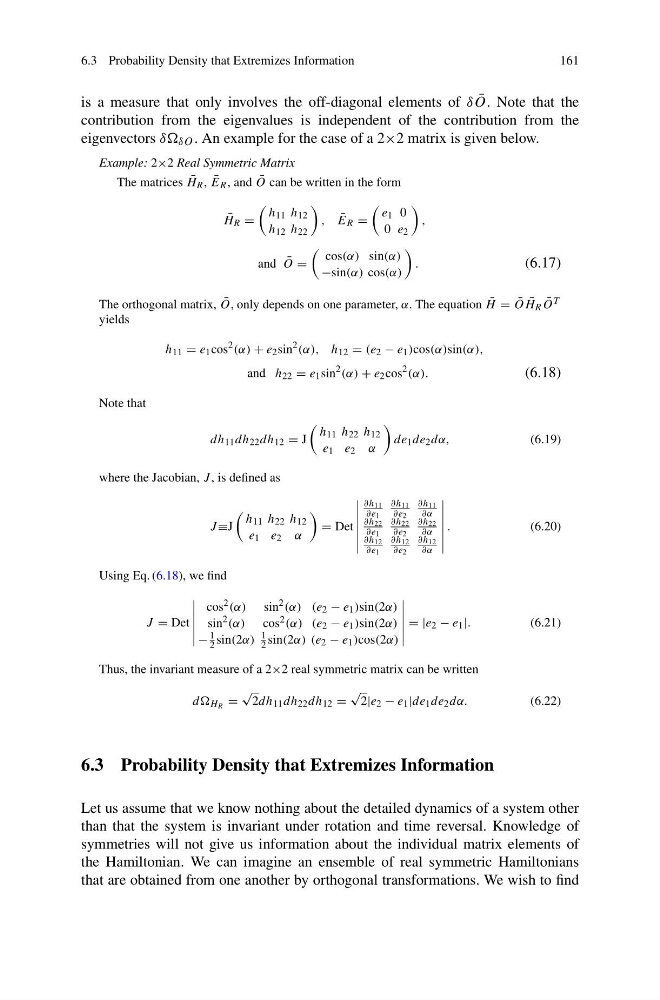
Example: 2×2 Real Symmetric Matrix
The matrices ¯
H R , ¯
E R , and ¯
O can be written in the form
¯
H R =
h 11 h 12
h 12 h 22
, ¯
E R =
e 1 0
0 e 2
,
and ¯
O =
cos(α) sin(α)
−sin(α) cos(α)
.
(6.17)
The orthogonal matrix, ¯
O, only depends on one parameter, α. The equation ¯
H = ¯
O ¯
H R ¯
O T
yields
h 11 = e 1 cos
2 (α) + e 2 sin
2 (α), h 12 = (e 2 − e 1 )cos(α)sin(α),
and h 22 = e 1 sin
2 (α) + e 2 cos
2 (α).
(6.18)
Note that
dh 11 dh 22 dh 12 = J
h 11 h 22 h 12
e 1 e 2 α
de 1 de 2 dα,
(6.19)
where the Jacobian, J , is defined as
J ≡J
h 11 h 22 h 12
e 1 e 2 α
= Det
∂h 11
∂e 1
∂h 11
∂e 2
∂h 11
∂α
∂h 22
∂e 1
∂h 22
∂e 2
∂h 22
∂α
∂h 12
∂e 1
∂h 12
∂e 2
∂h 12
∂α
.
(6.20)
Using Eq. (6.18), we find
J = Det
cos 2 (α) sin
2 (α) (e 2 − e 1 )sin(2α)
sin
2 (α) cos 2 (α) (e 2 − e 1 )sin(2α)
−
1
2 sin(2α)
1
2 sin(2α) (e 2 − e 1 )cos(2α)
= |e 2 − e 1 |.
(6.21)
Thus, the invariant measure of a 2×2 real symmetric matrix can be written
dd H R =
√
2dh 11 dh 22 dh 12 =
√
2|e 2 − e 1 |de 1 de 2 dα.
(6.22)
6.3 Probability Density that Extremizes Information
Let us assume that we know nothing about the detailed dynamics of a system other
than that the system is invariant under rotation and time reversal. Knowledge of
symmetries will not give us information about the individual matrix elements of
the Hamiltonian. We can imagine an ensemble of real symmetric Hamiltonians
that are obtained from one another by orthogonal transformations. We wish to find