

Three Partial Differential Equations in Curved Space and their Respective Solutions
497
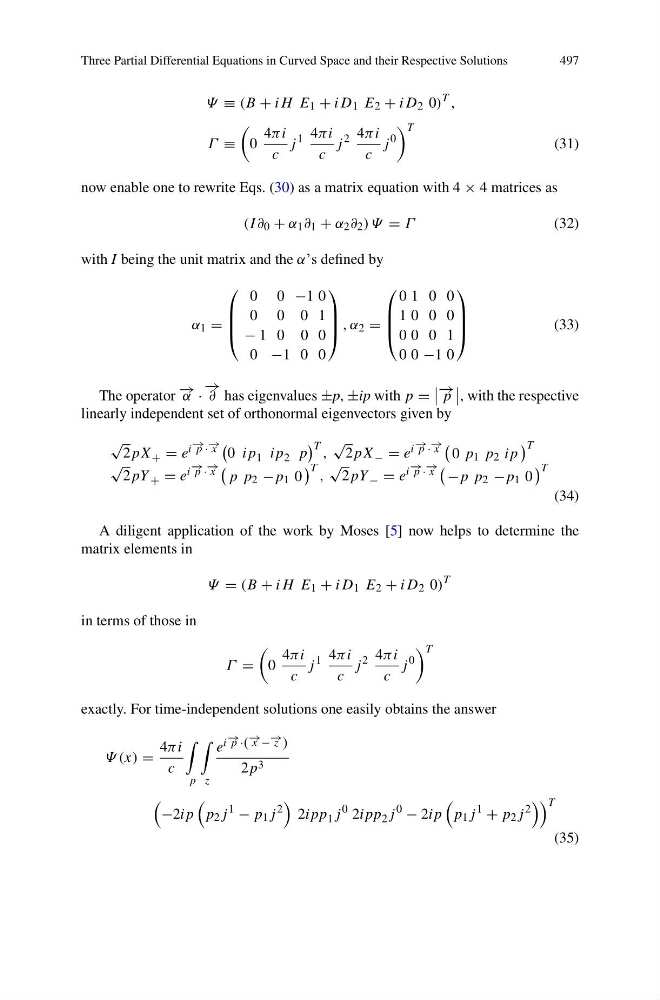
Ψ ≡ (B + iH E 1 + iD 1 E 2 + iD 2 0)
T ,
Γ ≡
0
4πi
c
j
1 4πi
c
j
2 4πi
c
j
0
T
(31)
now enable one to rewrite Eqs. (30) as a matrix equation with 4 × 4 matrices as
(I ∂ 0 + α 1 ∂ 1 + α 2 ∂ 2 ) Ψ = Γ
(32)
with I being the unit matrix and the α’s defined by
α 1 =
⎛
⎜
⎜
⎝
0 0 −1 0
0 0 0 1
− 1 0 0 0
0 −1 0 0
⎞
⎟
⎟
⎠ , α 2 =
⎛
⎜
⎜
⎝
0 1 0 0
1 0 0 0
0 0 0 1
0 0 −1 0
⎞
⎟
⎟
⎠
(33)
The operator − → α ·
− →
∂ has eigenvalues ±p, ±ip with p =
− → p
, with the respective
linearly independent set of orthonormal eigenvectors given by
√
2pX + = e i − → p · − → x
0 ip 1 ip 2 p
T ,
√
2pX − = e i − → p · − → x
0 p 1 p 2 ip
T
√
2pY + = e i − → p · − → x
p p 2 −p 1 0
T ,
√
2pY − = e i − → p · − → x −p p 2 −p 1 0
T
(34)
A diligent application of the work by Moses [5] now helps to determine the
matrix elements in
Ψ = (B + iH E 1 + iD 1 E 2 + iD 2 0)
T
in terms of those in
Γ =
0
4πi
c
j
1 4πi
c
j
2 4πi
c
j
0
T
exactly. For time-independent solutions one easily obtains the answer
Ψ (x) =
4πi
c
p
z
e i − → p ·( − → x − − → z )
2p 3
−2ip
p 2 j
1
− p 1 j
2
2ipp 1 j
0 2ipp 2 j
0
− 2ip
p 1 j
1
+ p 2 j
2
T
(35)