

Tachyons and Representations of Sp(2, R)
135
D(g)
where
Y commutes with all elements of D(g) and satisfies the equation
Y 4 + D
2
Y 2 + D
4 = 0 with D
2 =
D 2 +
5
2 I
and D
4 =
D 4 +
1
4 D 2 +
9
16 I
.
(I is the identity in
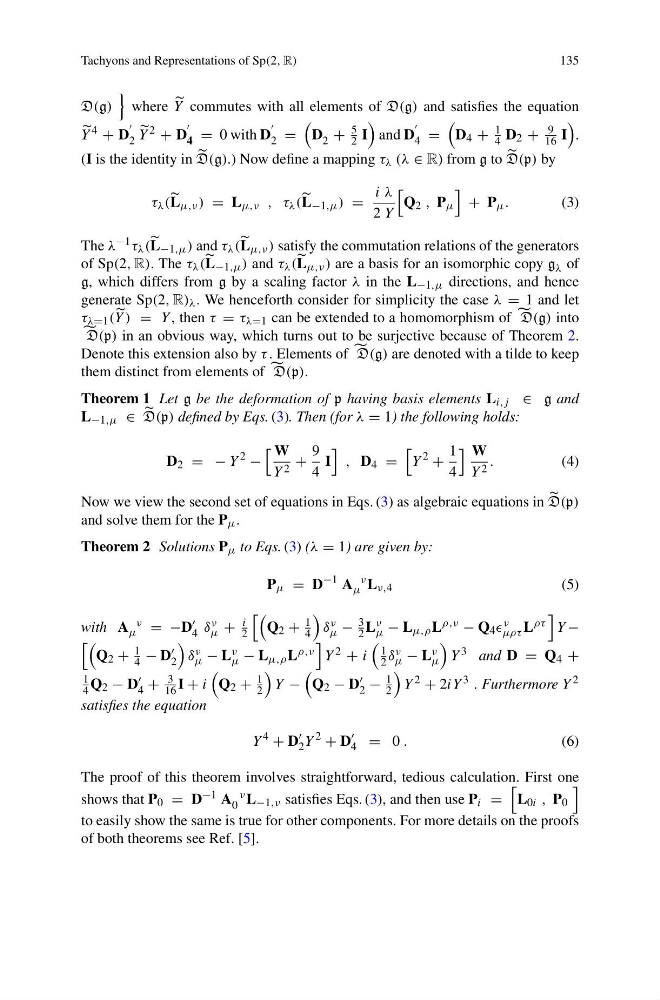
D(g).) Now define a mapping τ λ (λ ∈ R) from g to
D(p) by
τ λ ( L μ,ν ) = L μ,ν , τ λ ( L −1,μ ) =
i λ
2 Y
Q 2 , P μ
+ P μ .
(3)
The λ −1 τ λ ( L −1,μ ) and τ λ ( L μ,ν ) satisfy the commutation relations of the generators
of Sp(2, R). The τ λ ( L −1,μ ) and τ λ ( L μ,ν ) are a basis for an isomorphic copy g λ of
g, which differs from g by a scaling factor λ in the L −1,μ directions, and hence
generate Sp(2, R) λ . We henceforth consider for simplicity the case λ = 1 and let
τ λ=1 (
Y ) = Y , then τ = τ λ=1 can be extended to a homomorphism of D(g) into
D(p) in an obvious way, which turns out to be surjective because of Theorem 2.
Denote this extension also by τ . Elements of D(g) are denoted with a tilde to keep
them distinct from elements of D(p).
Theorem 1 Let g be the deformation of p having basis elements L i,j ∈ g and
L −1,μ ∈
D(p) defined by Eqs. (3). Then (for λ = 1) the following holds:
D 2 = − Y
2
−
W
Y 2 +
9
4
I
, D 4 =
Y
2
+
1
4
W
Y 2 .
(4)
Now we view the second set of equations in Eqs. (3) as algebraic equations in
D(p)
and solve them for the P μ .
Theorem 2 Solutions P μ to Eqs. (3) (λ = 1) are given by:
P μ = D
−1 A
ν
μ L ν,4
(5)
with A ν
μ = −D
4 δ ν
μ +
i
2
Q 2 +
1
4
δ ν
μ −
3
2 L ν
μ − L μ,ρ L ρ,ν − Q 4 ν
μρτ L ρτ
Y −
Q 2 +
1
4 − D
2
δ ν
μ − L ν
μ − L μ,ρ L ρ,ν
Y 2 + i
1
2 δ ν
μ − L ν
μ
Y 3 and D = Q 4 +
1
4 Q 2 − D
4 +
3
16 I + i
Q 2 +
1
2
Y −
Q 2 − D
2 −
1
2
Y 2 + 2iY 3 . Furthermore Y 2
satisfies the equation
Y
4
+ D
2 Y
2
+ D
4 = 0 .
(6)
The proof of this theorem involves straightforward, tedious calculation. First one
shows that P 0 = D −1 A ν
0 L −1,ν satisfies Eqs. (3), and then use P i =
L 0i , P 0
to easily show the same is true for other components. For more details on the proofs
of both theorems see Ref. [5].