

262
5 Plasticity
with t = 0.1 are computed. Plastic time steps are emphasized by larger hollow
circles, whereas elastic time steps are indicated by smaller filled circles.
Figure 5.26b showcases the resulting strain history (t) that displays an initial
elastic phase with ˙
(t) = ˙
σ(t), a subsequent plastic phase with ˙
(t) = ˙
σ(t) × 11 (thus
in particular during the holding phase (t) = 1/1 + 4 × 11 = 45), a second elastic
phase with ˙
(t) = ˙
σ(t), and a final plastic phase with ˙
(t) = ˙
σ(t) × 11, respectively.
The resulting parallelogram-type σ = σ() diagram is highlighted in Fig. 5.26c.
It is easy to verify that the strain varies between 45 and 43 in the second elastic phase
(and between 0 and 1 in the initial elastic phase).
Figure 5.26d demonstrates the plastic strain history p (t): during the plastic phase
p (t) evolves with |˙ p (t)| = |˙ (t) − ˙
σ(t)/E| = 55 − 5/1 = 50, whereas p (t) stays
constant with p (t) = 40 (or as initial value p (t) = 0) during the second elastic
phase.
Finally, the plastic arc-length κ(t) in Fig. 5.26e follows constant-linear-constantlinear in time from integrating ˙
κ(t) = |˙ p (t)| = {0, 50, 0, 50} over the time interval
t ∈ [0, t max = 10], thus κ max = 40 + 30 = 70.
5.3.7 Specific Prandtl Mixed Hardening Model: Formulation
The specific Prandtl (isotropic and kinematic) mixed hardening model, similar to that
displayed in Fig. 5.12 (however with the hardening modulus H and the hardening
strain ε h coinciding here with the isotropic- and kinematic-hardening moduli H
and K , respectively, and the isotropic- and kinematic-hardening strains hi and hk ,
respectively), consists of a serial arrangement of (1) a linear elastic spring with
stiffness E and (2) a linear mixed-hardening frictional slider consisting of a parallel
arrangement of (i) a linear frictional slider with threshold σ y and (ii) linear mixedhardening springs with stiffnesses H and K (the isotropic- and kinematic-hardening
moduli).
For the specific Prandtl mixed hardening model the free energy density ψ is
expressed as a quadratic (and thus convex) function of − p (i.e. the elastic strain
e ), hi (the isotropic-hardening strain) and hk (the kinematic-hardening strain)
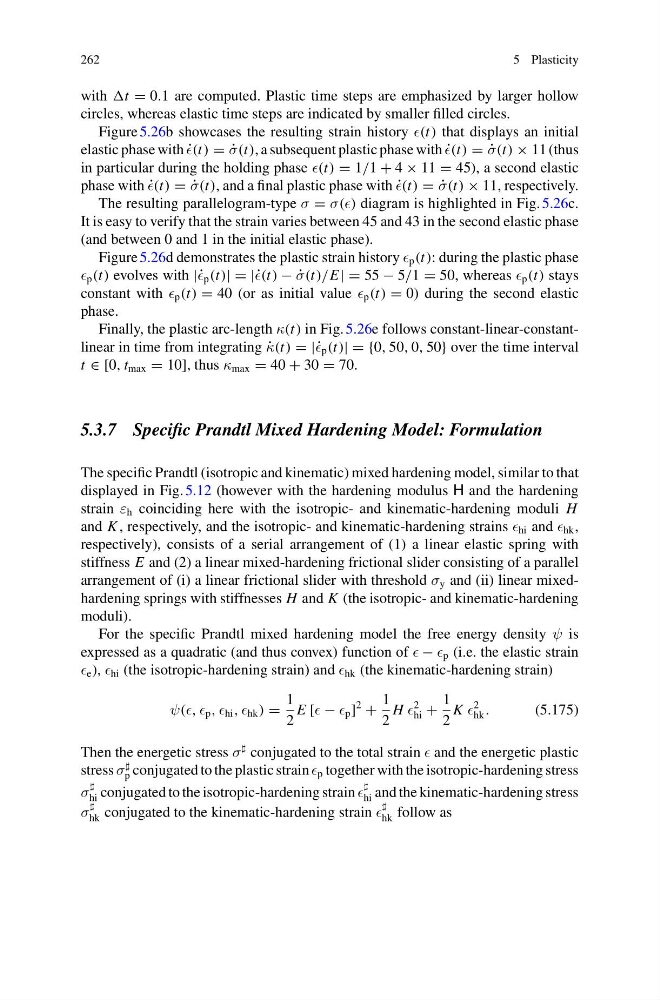
ψ(, p , hi , hk ) =
1
2
E [ − p ]
2
+
1
2
H
2
hi +
1
2
K
2
hk .
(5.175)
Then the energetic stress σ
conjugated to the total strain and the energetic plastic
stress σ
p conjugated to the plastic strain p together with the isotropic-hardening stress
σ
hi conjugated to the isotropic-hardening strain
hi and the kinematic-hardening stress
σ
hk conjugated to the kinematic-hardening strain
hk follow as