

5.2 Prandtl Model
215
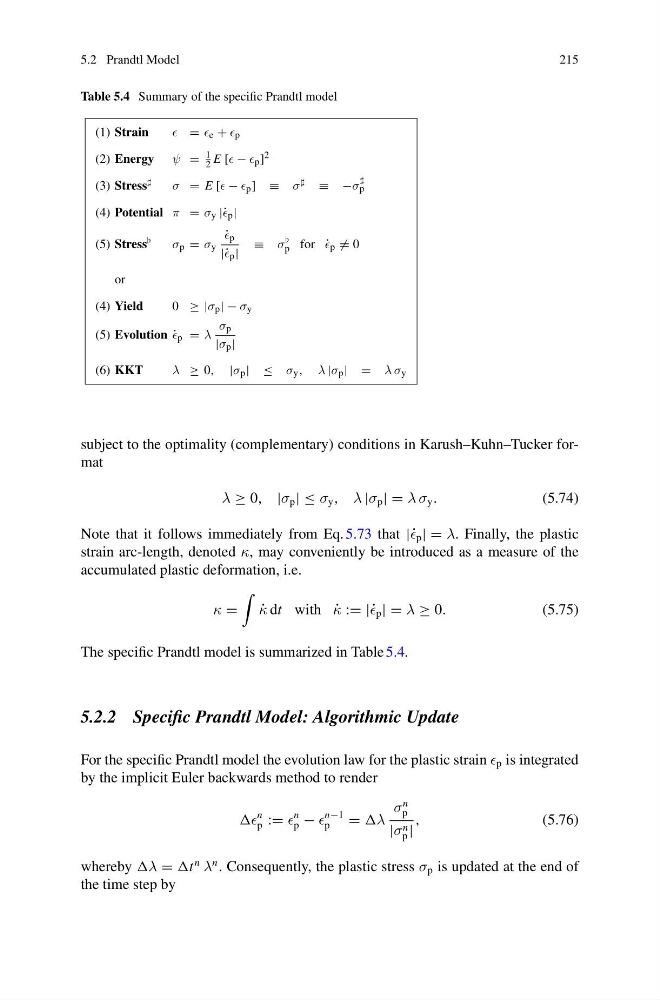
Table 5.4 Summary of the specific Prandtl model
(1) Strain
= e + p
(2) Energy ψ =
1
2 E [ − p ] 2
(3) Stress
σ = E [ − p ] ≡ σ ≡ −σ
p
(4) Potential π = σ y |˙ p |
(5) Stress
σ p = σ y
˙
p
|˙ p |
≡ σ
p for ˙
p = 0
or
(4) Yield
0 ≥ |σ p | − σ y
(5) Evolution ˙
p = λ
σ p
|σ p |
(6) KKT
λ ≥ 0, |σ p | ≤ σ y , λ |σ p | = λ σ y
subject to the optimality (complementary) conditions in Karush–Kuhn–Tucker format
λ ≥ 0, |σ p | ≤ σ y , λ |σ p | = λ σ y .
(5.74)
Note that it follows immediately from Eq. 5.73 that |˙ p | = λ. Finally, the plastic
strain arc-length, denoted κ, may conveniently be introduced as a measure of the
accumulated plastic deformation, i.e.
κ =
˙
κ dt with ˙
κ := |˙ p | = λ ≥ 0.
(5.75)
The specific Prandtl model is summarized in Table 5.4.
5.2.2 Specific Prandtl Model: Algorithmic Update
For the specific Prandtl model the evolution law for the plastic strain p is integrated
by the implicit Euler backwards method to render
n
p :=
n
p −
n−1
p
= λ
σ
n
p
|σ n
p |
,
(5.76)
whereby λ = t
n
λ
n . Consequently, the plastic stress σ p is updated at the end of
the time step by