

6.3 Hydrodynamic Interactions
85
F x 12 = F 12
x 12
r 12
F y 12 = F 12
y 12
r 12
(6.8)
F z 12 = F 12
z 12
r 12
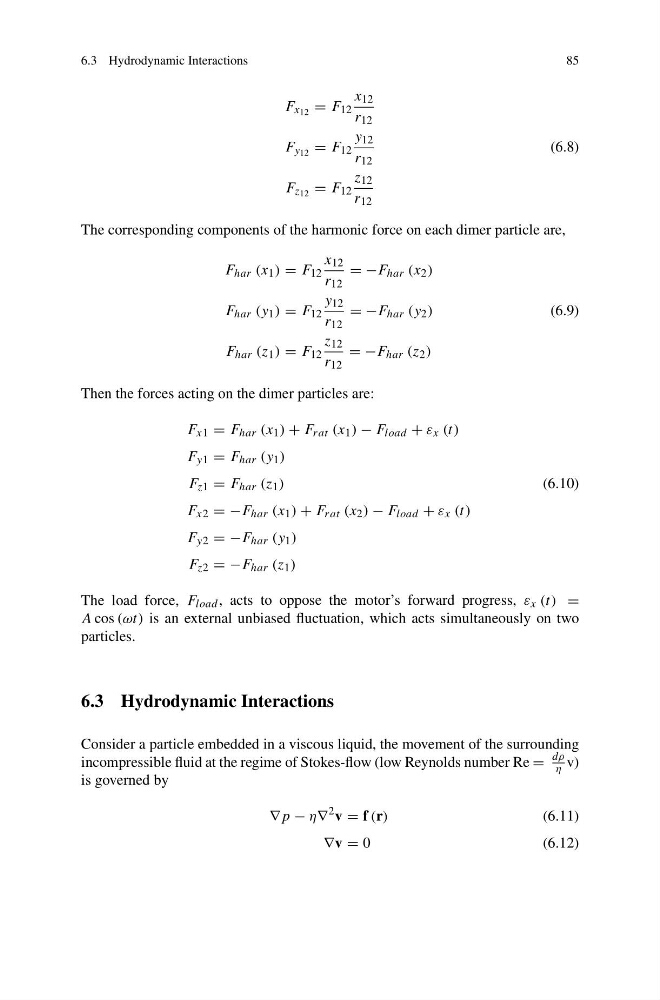
The corresponding components of the harmonic force on each dimer particle are,
F har (x 1 ) = F 12
x 12
r 12
= −F har (x 2 )
F har (y 1 ) = F 12
y 12
r 12
= −F har (y 2 )
(6.9)
F har (z 1 ) = F 12
z 12
r 12
= −F har (z 2 )
Then the forces acting on the dimer particles are:
F x1 = F har (x 1 ) + F rat (x 1 ) − F load + ε x (t)
F y1 = F har (y 1 )
F z1 = F har (z 1 )
(6.10)
F x2 = −F har (x 1 ) + F rat (x 2 ) − F load + ε x (t)
F y2 = −F har (y 1 )
F z2 = −F har (z 1 )
The load force, F load , acts to oppose the motor’s forward progress, ε x (t) =
A cos (ωt) is an external unbiased fluctuation, which acts simultaneously on two
particles.
6.3 Hydrodynamic Interactions
Consider a particle embedded in a viscous liquid, the movement of the surrounding
incompressible fluid at the regime of Stokes-flow (low Reynolds number Re =
dρ
η v)
is governed by
∇p − η∇
2 v = f (r)
(6.11)
∇v = 0
(6.12)