

40
3 Biased Brownian Motion
x
t n+1
= x (t n ) −
D
k B T
V (x (t n )) t + η (t n ) F DN
D
k B T
t + F load
D
2k B T
t + (2DDt) 1/2 rand n
(3.40)
with
V
(x (t n )) = ±
V o
L
cos
2πx (t n )
L
−
1
2
cos
4πx (t n )
L
(3.41)
where F load is the load force and F DN = |±F | is the dichotomous noise force. In
dimensionless units the former equations transform (Figs. 3.17, 3.18, and 3.19):
˜
x
t n+1
= ˜
x
t n
−
D
V 0
V
˜
x
t n
˜ t + η
t n
D
F DN ˜ t +
D
F load ˜ t +
2
DD˜ t
1/2 rand n
(3.42)
with,
V
˜
x
t n
= ±
cos
2π ˜
x
t n
−
1
2
cos
4π ˜
x
˜
t n
(3.43)
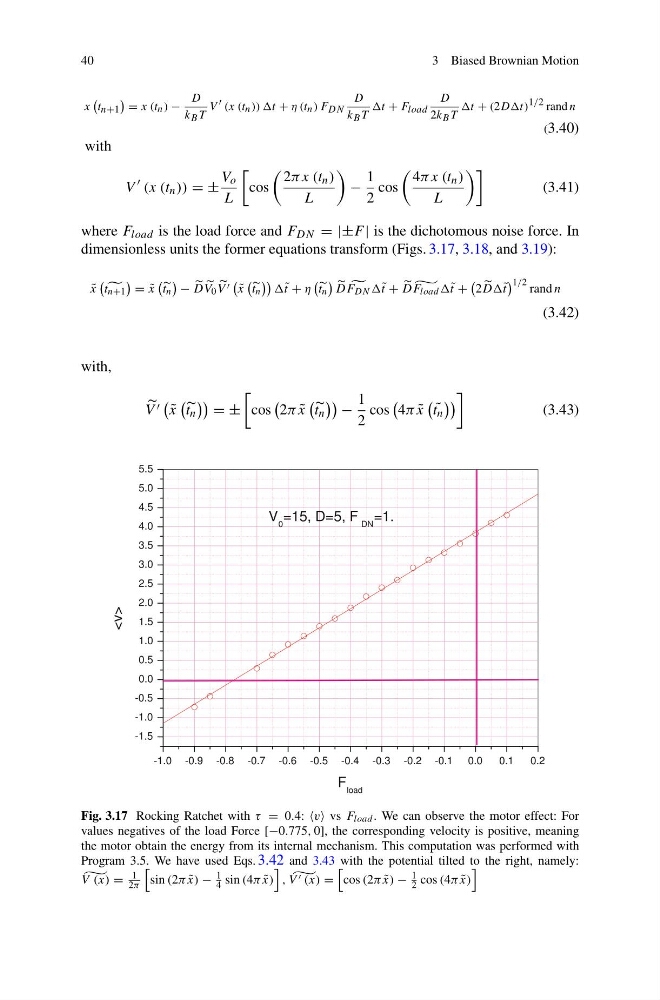
Fig. 3.17 Rocking Ratchet with τ = 0.4: v vs F load . We can observe the motor effect: For
values negatives of the load Force [−0.775, 0], the corresponding velocity is positive, meaning
the motor obtain the energy from its internal mechanism. This computation was performed with
Program 3.5. We have used Eqs. 3.42 and 3.43 with the potential tilted to the right, namely:
V (x) =
1
2π
sin (2π ˜
x) −
1
4 sin (4π ˜
x)
,
V (x) =
cos (2π ˜
x) −
1
2 cos (4π ˜
x)