

4.3 Numeral Examples
67
0
10
20
30
40
50
60
70
80
90
100
1
1.2
1.4
1.6
1.8
2
2.2
2.4
2.6
2.8
3
t/s
mode
mode
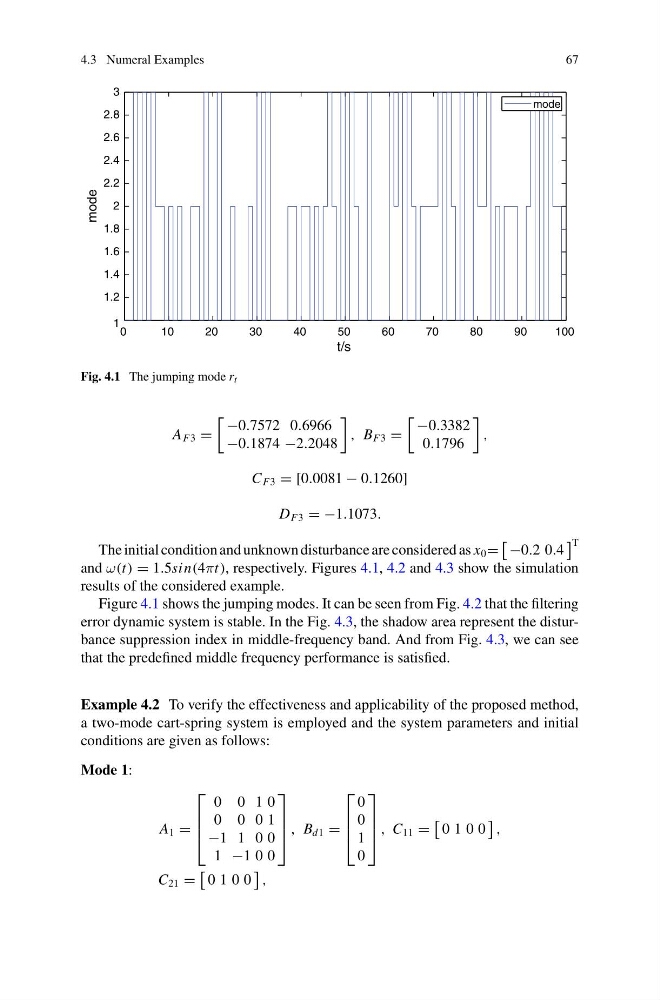
Fig. 4.1 The jumping mode r t
A F3 =
−0.7572 0.6966
−0.1874 −2.2048
, B F3 =
−0.3382
0.1796
,
C F3 = [0.0081 − 0.1260]
D F3 = −1.1073.
The initial condition and unknown disturbance are considered as x 0 =
−0.2 0.4
T
and ω(t) = 1.5sin(4πt), respectively. Figures 4.1, 4.2 and 4.3 show the simulation
results of the considered example.
Figure 4.1 shows the jumping modes. It can be seen from Fig. 4.2 that the filtering
error dynamic system is stable. In the Fig. 4.3, the shadow area represent the disturbance suppression index in middle-frequency band. And from Fig. 4.3, we can see
that the predefined middle frequency performance is satisfied.
Example 4.2 To verify the effectiveness and applicability of the proposed method,
a two-mode cart-spring system is employed and the system parameters and initial
conditions are given as follows:
Mode 1:
A 1 =
⎡
⎢
⎢
⎣
0 0 1 0
0 0 0 1
−1 1 0 0
1 −1 0 0
⎤
⎥
⎥
⎦ , B d1 =
⎡
⎢
⎢
⎣
0
0
1
0
⎤
⎥
⎥
⎦ , C 11 =
0 1 0 0
,
C 21 =
0 1 0 0
,