

4.2 Multiple Frequency Robust Filtering for Multi-model Jumping System
65
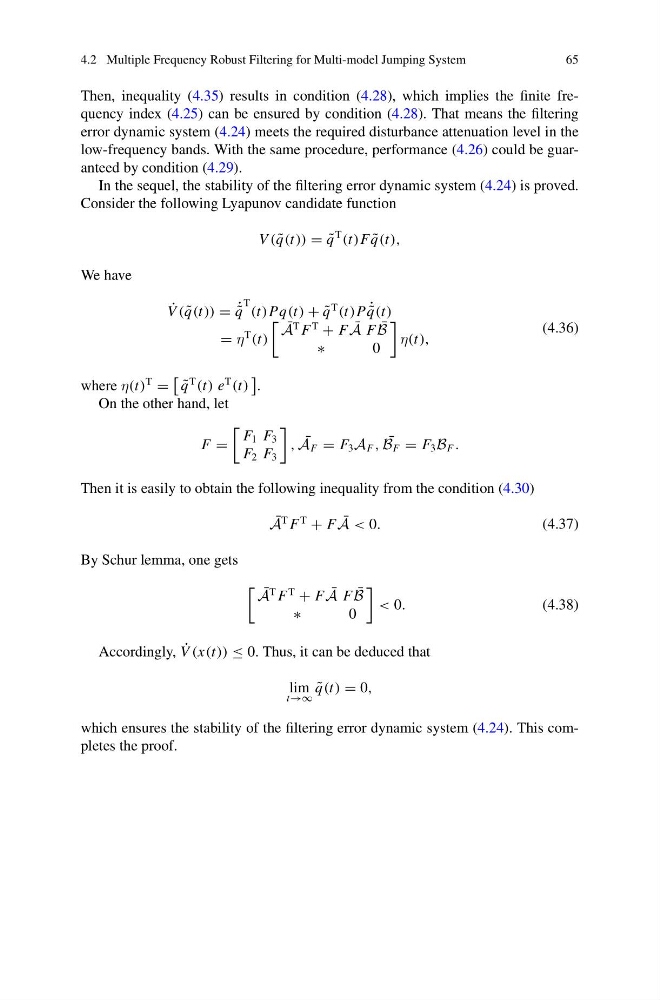
Then, inequality (4.35) results in condition (4.28), which implies the finite frequency index (4.25) can be ensured by condition (4.28). That means the filtering
error dynamic system (4.24) meets the required disturbance attenuation level in the
low-frequency bands. With the same procedure, performance (4.26) could be guaranteed by condition (4.29).
In the sequel, the stability of the filtering error dynamic system (4.24) is proved.
Consider the following Lyapunov candidate function
V ( ˜
q(t)) = ˜
q
T
(t)F ˜
q(t),
We have
˙
V ( ˜
q(t)) = ˙ ˜
q
T (t)Pq(t) + ˜
q
T
(t)P ˙ ˜
q(t)
= η
T
(t)
¯
A
T F
T
+ F ¯
A F ¯
B
∗
0
η(t),
(4.36)
where η(t)
T
=
˜
q
T
(t) e
T
(t)
.
On the other hand, let
F =
F 1 F 3
F 2 F 3
, ¯
A F = F 3 A F , ¯
B F = F 3 B F .
Then it is easily to obtain the following inequality from the condition (4.30)
¯
A
T F
T
+ F ¯
A < 0.
(4.37)
By Schur lemma, one gets
¯
A
T F
T
+ F ¯
A F ¯
B
∗
0
< 0.
(4.38)
Accordingly, ˙
V (x(t)) ≤ 0. Thus, it can be deduced that
lim
t→∞
˜
q(t) = 0,
which ensures the stability of the filtering error dynamic system (4.24). This completes the proof.