

12
1 Introduction
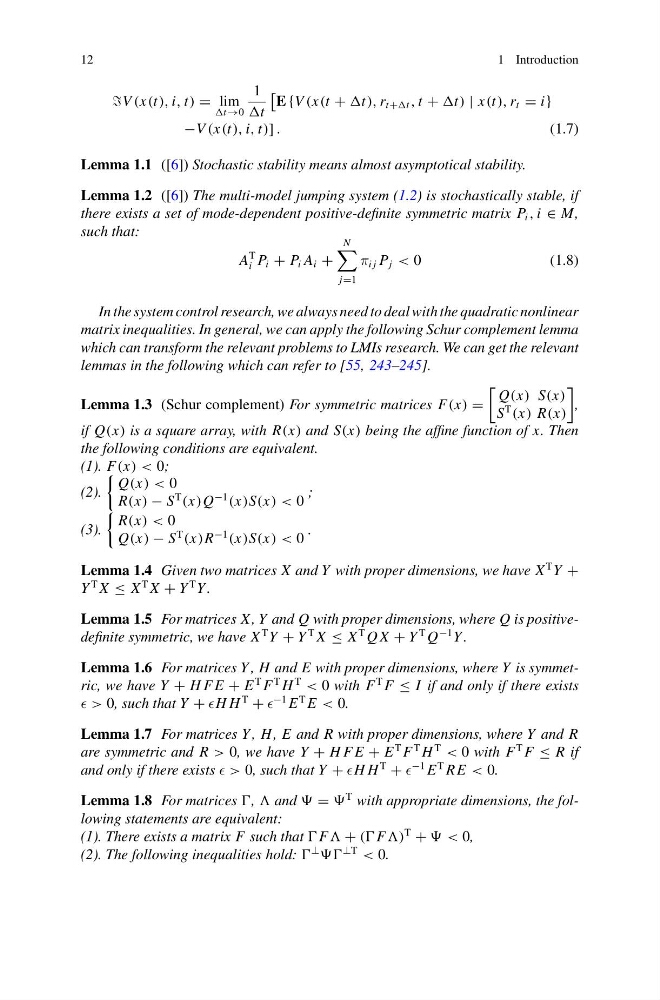
V (x(t), i, t) = lim
t→0
1
t
E {V (x(t + t), r t+t , t + t) | x(t), r t = i}
−V (x(t), i, t)] .
(1.7)
Lemma 1.1 ([6]) Stochastic stability means almost asymptotical stability.
Lemma 1.2 ([6]) The multi-model jumping system (1.2) is stochastically stable, if
there exists a set of mode-dependent positive-definite symmetric matrix P i , i ∈ M,
such that:
A
T
i P i + P i A i +
N
j=1
π i j P j < 0
(1.8)
In the system control research, we always need to deal with the quadratic nonlinear
matrix inequalities. In general, we can apply the following Schur complement lemma
which can transform the relevant problems to LMIs research. We can get the relevant
lemmas in the following which can refer to [55, 243–245].
Lemma 1.3 (Schur complement) For symmetric matrices F(x) =
Q(x) S(x)
S
T
(x) R(x)
,
if Q(x) is a square array, with R(x) and S(x) being the affine function of x. Then
the following conditions are equivalent.
(1). F(x) < 0;
(2).
Q(x) < 0
R(x) − S
T
(x)Q
−1
(x)S(x) < 0
;
(3).
R(x) < 0
Q(x) − S
T
(x)R
−1
(x)S(x) < 0
.
Lemma 1.4 Given two matrices X and Y with proper dimensions, we have X
T Y +
Y
T X ≤ X
T X + Y
T Y .
Lemma 1.5 For matrices X , Y and Q with proper dimensions, where Q is positivedefinite symmetric, we have X
T Y + Y
T X ≤ X
T Q X + Y
T Q
−1 Y .
Lemma 1.6 For matrices Y , H and E with proper dimensions, where Y is symmetric, we have Y + H F E + E
T F
T H
T
< 0 with F
T F ≤ I if and only if there exists
> 0, such that Y + H H
T
+
−1 E
T E < 0.
Lemma 1.7 For matrices Y , H , E and R with proper dimensions, where Y and R
are symmetric and R > 0, we have Y + H F E + E
T F
T H
T
< 0 with F
T F ≤ R if
and only if there exists > 0, such that Y + H H
T
+
−1 E
T R E < 0.
Lemma 1.8 For matrices , and =
T with appropriate dimensions, the following statements are equivalent:
(1). There exists a matrix F such that F + (( F)
T
+ < 0,
(2). The following inequalities hold:
⊥
⊥T
< 0.