

10
1 Introduction
range is not given directly. In the end, the more complex the weighting function is,
the larger the controller dimension is, which makes it difficult to solve the state space
equation. Therefore, the research of frequency weighting method develops slowly.
The GKYP lemma is a new method to solve the finite frequency problem [240–
242]. By GKYP lemma, the finite frequency domain characteristics is equivalent
to linear matrix inequalities. Comparing with other finite frequency performance
research methods, GKYP lemma has the following advantages: (1) There is a rigorous
mathematical derivation process; (2) It has perfect basic theory of finite frequency
performance; (3) The performance shows a clear meaning in frequency domain.
1.4 Some Main Definitions and Lemmas
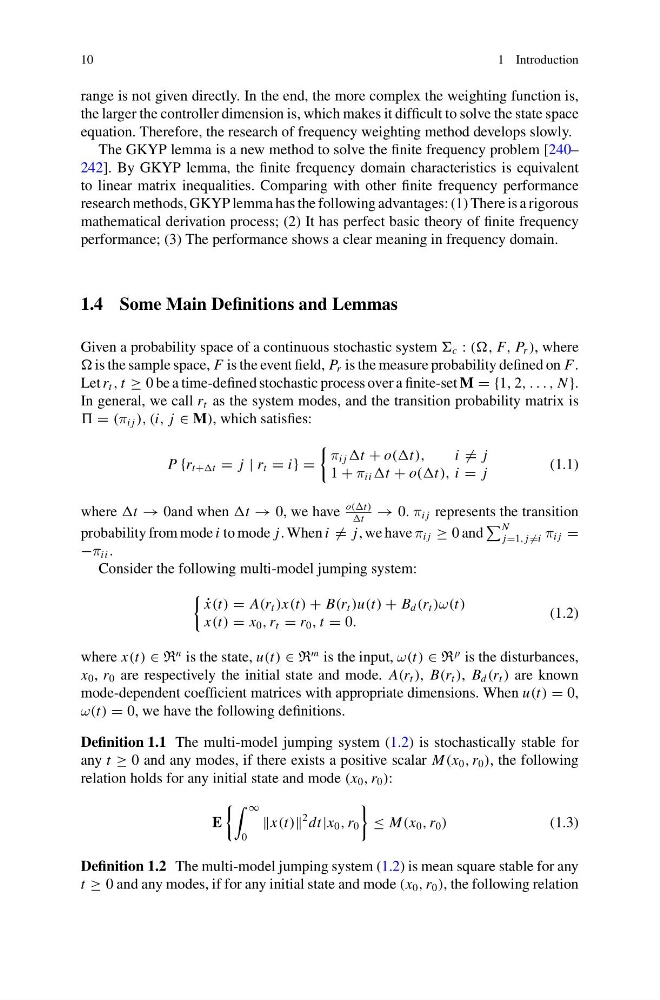
Given a probability space of a continuous stochastic system c : ((, F, P r ), where
is the sample space, F is the event field, P r is the measure probability defined on F.
Let r t , t ≥ 0 be a time-defined stochastic process over a finite-set M = {1, 2, . . . , N }.
In general, we call r t as the system modes, and the transition probability matrix is
= (π i j ), (i, j ∈ M), which satisfies:
P {r t+t = j | r t = i} =
π i j t + o((t),
i = j
1 + π ii t + o((t), i = j
(1.1)
where t → 0and when t → 0, we have
o((t)
t
→ 0. π i j represents the transition
probability from mode i to mode j. When i = j, we have π i j ≥ 0 and
N
j=1, j =i π i j =
−π ii .
Consider the following multi-model jumping system:
˙
x(t) = A(r t )x(t) + B(r t )u(t) + B d (r t )ω(t)
x(t) = x 0 , r t = r 0 , t = 0.
(1.2)
where x(t) ∈ R
n is the state, u(t) ∈ R
m is the input, ω(t) ∈ R
p is the disturbances,
x 0 , r 0 are respectively the initial state and mode. A(r t ), B(r t ), B d (r t ) are known
mode-dependent coefficient matrices with appropriate dimensions. When u(t) = 0,
ω(t) = 0, we have the following definitions.
Definition 1.1 The multi-model jumping system (1.2) is stochastically stable for
any t ≥ 0 and any modes, if there exists a positive scalar M(x 0 , r 0 ), the following
relation holds for any initial state and mode (x 0 , r 0 ):
E
∞
0
x(t)
2 dt|x 0 , r 0
≤ M(x 0 , r 0 )
(1.3)
Definition 1.2 The multi-model jumping system (1.2) is mean square stable for any
t ≥ 0 and any modes, if for any initial state and mode (x 0 , r 0 ), the following relation