

8.1 Robust FDF Design for Fuzzy Multi-model Jumping System
149
S
i=1
h
2
i ii (r ) +
S
i=1
h i
S
i=1
h j
i j (r ) + ji (r )
< 0.
(8.39)
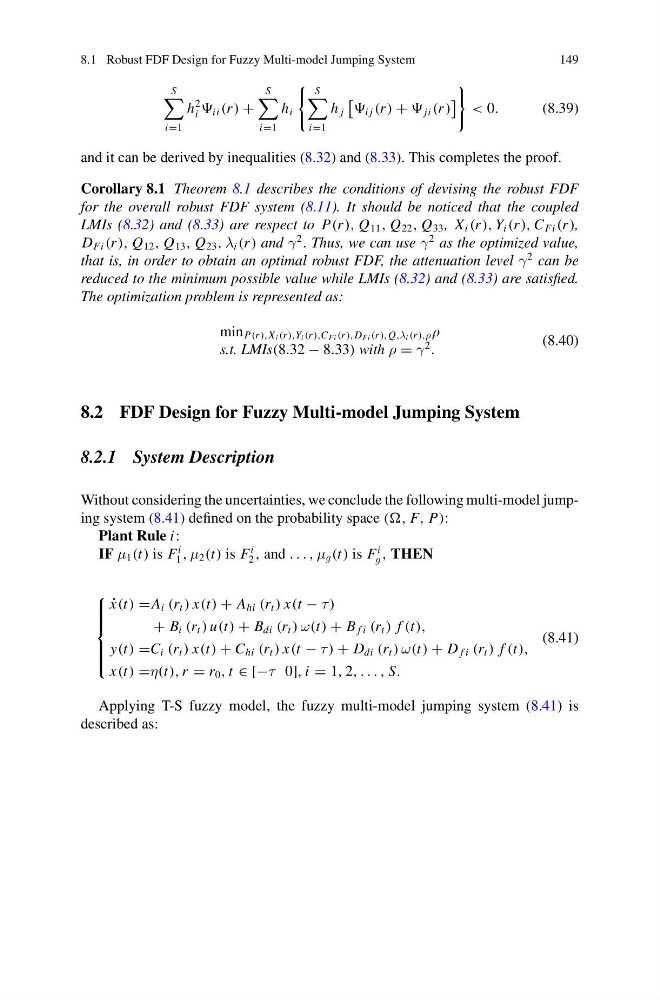
and it can be derived by inequalities (8.32) and (8.33). This completes the proof.
Corollary 8.1 Theorem 8.1 describes the conditions of devising the robust FDF
for the overall robust FDF system (8.11). It should be noticed that the coupled
LMIs (8.32) and (8.33) are respect to P(r ), Q 11 , Q 22 , Q 33 , X i (r ), Y i (r ), C Fi (r ),
D Fi (r ), Q 12 , Q 13 , Q 23 , λ i (r ) and γ
2
. Thus, we can use γ
2 as the optimized value,
that is, in order to obtain an optimal robust FDF, the attenuation level γ
2 can be
reduced to the minimum possible value while LMIs (8.32) and (8.33) are satisfied.
The optimization problem is represented as:
min P(r ),X i (r ),Y i (r ),C Fi (r ),D Fi (r ),Q,λ i (r ),ρ ρ
s.t. LMIs(8.32 − 8.33) with ρ = γ
2
.
(8.40)
8.2 FDF Design for Fuzzy Multi-model Jumping System
8.2.1 System Description
Without considering the uncertainties, we conclude the following multi-model jumping system (8.41) defined on the probability space ((, F, P):
Plant Rule i:
IF μ 1 (t) is F
i
1 , μ 2 (t) is F
i
2 , and . . . , μ g (t) is F
i
g , THEN
⎧
⎪ ⎪ ⎪ ⎨
⎪ ⎪ ⎪ ⎩
˙
x(t) =A i (r t ) x(t) + A hi (r t ) x(t − τ )
+ B i (r t ) u(t) + B di (r t ) ω(t) + B f i (r t ) f (t),
y(t) =C i (r t ) x(t) + C hi (r t ) x(t − τ ) + D di (r t ) ω(t) + D f i (r t ) f (t),
x(t) =η(t), r = r 0 , t ∈ [−τ 0], i = 1, 2, . . . , S.
(8.41)
Applying T-S fuzzy model, the fuzzy multi-model jumping system (8.41) is
described as: