

126
7 Observer-Based Robust Fault Detection for Fuzzy Multi-model Jumping System
model jumping system (7.26) is stochastically stable can be obtained. The proof is
completed.
Next we need to achieve the goal of improving the sensitivity to faults. Letting
ω(t) = 0, the error dynamic multi-model jumping system is described as:
˙ ˆ
x(t) = ˆ
A i j (r ) ˆ
x(t) + ˆ
A hi j (r ) ˆ
x h (t) + ˆ
B f i j (r ) f (t),
r f (t) = ˆ
C i j (r ) ˆ
x(t) + ˆ
C hi j (r ) ˆ
x h (t) + ˆ
D f i (r ) f (t).
(7.32)
In order to design the parameter matrix H i (r ) and make the error dynamic
multi-model jumping system (7.32) be stochastically stable for all non-zero f (t) ∈
L 2 [0, ∞), we present another performance index:
E
∞
0
f
T
(t)r f (t)dt
γE
∞
0
f
T
(t) f (t)dt
ω(t)=0
.
(7.33)
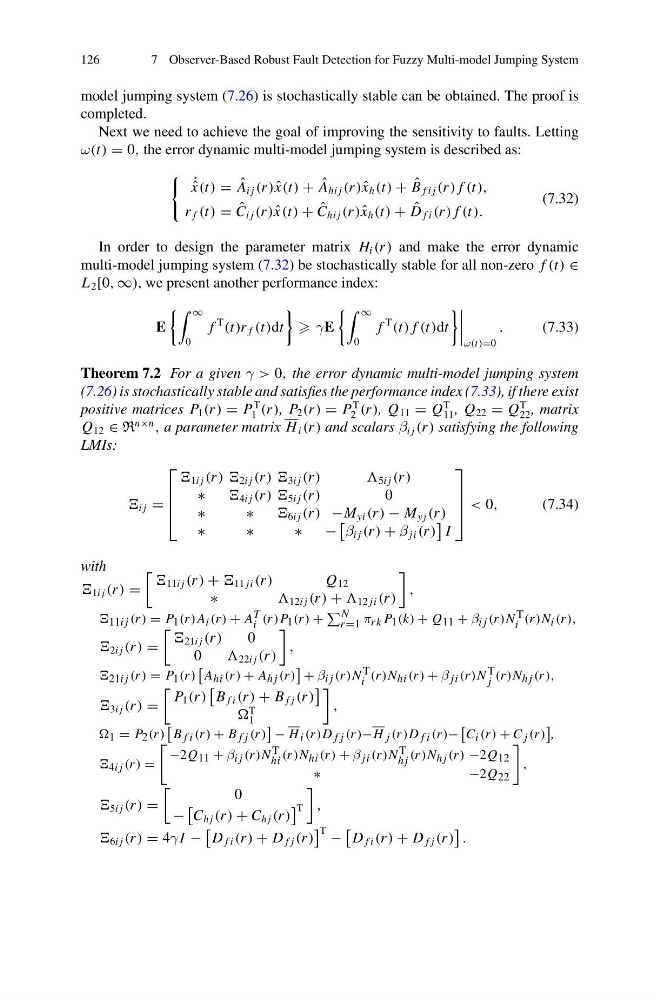
Theorem 7.2 For a given γ > 0, the error dynamic multi-model jumping system
(7.26) is stochastically stable and satisfies the performance index (7.33), if there exist
positive matrices P 1 (r ) = P
T
1 (r ), P 2 (r ) = P
T
2 (r ), Q 11 = Q
T
11 , Q 22 = Q
T
22 , matrix
Q 12 ∈ R
n×n
, a parameter matrix H i (r ) and scalars β i j (r ) satisfying the following
LMIs:
i j =
⎡
⎢
⎢
⎣
1i j (r ) ) 2i j (r ) ) 3i j (r )
) 5i j (r )
∗
4i j (r ) ) 5i j (r )
0
∗
∗
6i j (r ) −M yi (r ) − M yj (r )
∗
∗
∗
−
β i j (r ) + β ji (r )
I
⎤
⎥
⎥
⎦ < 0,
(7.34)
with
1i j (r ) =
11i j (r ) + 11 ji (r )
Q 12
∗
12i j (r ) + 12 ji (r )
,
11i j (r ) = P 1 (r )A i (r ) + A T
i (r )P 1 (r ) +
N
r =1 π rk P 1 (k) + Q 11 + β i j (r )N T
i (r )N i (r ),
2i j (r ) =
21i j (r )
0
0
22i j (r )
,
21i j (r ) = P 1 (r )
A hi (r ) + A h j (r )
+ β i j (r )N T
i (r )N hi (r ) + β ji (r )N T
j (r )N h j (r ),
3i j (r ) =
P 1 (r )
B f i (r ) + B f j (r )
T
1
,
1 = P 2 (r )
B f i (r ) + B f j (r )
− H i (r )D f j (r )−H j (r )D f i (r )−
C i (r ) + C j (r )
,
4i j (r ) =
−2Q 11 + β i j (r )N T
hi (r )N hi (r ) + β ji (r )N T
h j (r )N h j (r ) −2Q 12
∗
− 2Q 22
,
5i j (r ) =
0
−
C h j (r ) + C h j (r )
T
,
6i j (r ) = 4γ I −
D f i (r ) + D f j (r )
T −
D f i (r ) + D f j (r )
.