

100
6 Robust Fault Detection for Multi-model Jumping System
V ( ˜
x(t), r ) = ˜
x
T
(t) ˜
P i ˜
x(t) +
t
t−τ
˜
x
T
(s) ˜
Q ˜
x(s)ds,
(6.12)
where ˜
P i > 0, ˜
Q > 0 are the given mode-dependent symmetric matrices.
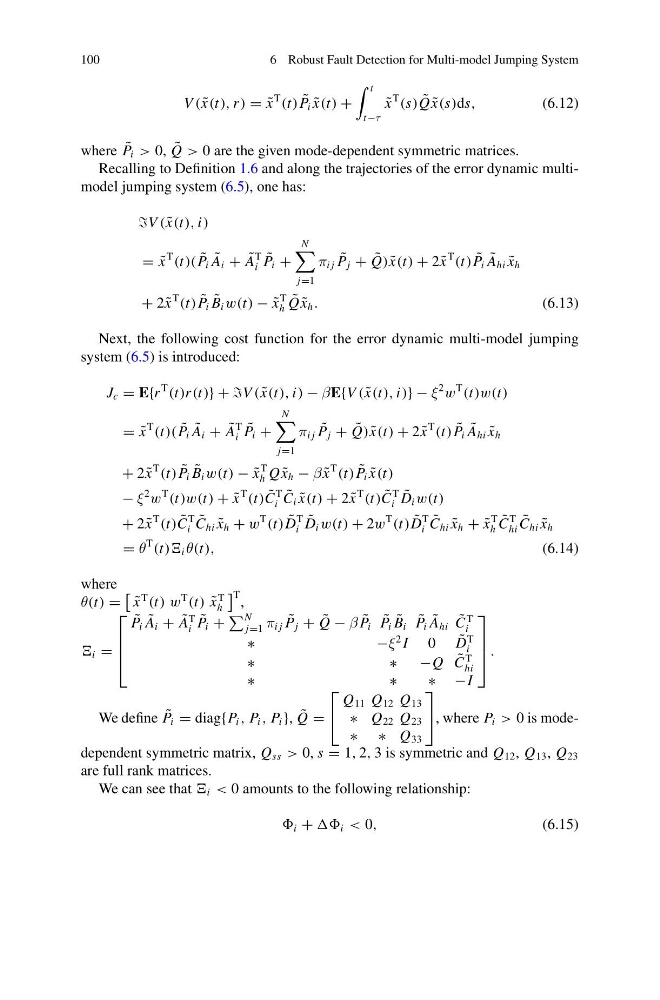
Recalling to Definition 1.6 and along the trajectories of the error dynamic multimodel jumping system (6.5), one has:
V ( ˜
x(t), i)
= ˜
x
T
(t)( ˜
P i ˜
A i + ˜
A
T
i
˜
P i +
N
j=1
π i j ˜
P j + ˜
Q) ˜
x(t) + 2 ˜
x
T
(t) ˜
P i ˜
A hi ˜
x h
+ 2 ˜
x
T
(t) ˜
P i ˜
B i w(t) − ˜
x
T
h
˜
Q ˜
x h .
(6.13)
Next, the following cost function for the error dynamic multi-model jumping
system (6.5) is introduced:
J c = E{r
T
(t)r (t)} + +V ( ˜
x(t), i) − βE{V ( ˜
x(t), i)} − ξ
2
w
T
(t)w(t)
= ˜
x
T
(t)( ˜
P i ˜
A i + ˜
A
T
i
˜
P i +
N
j=1
π i j ˜
P j + ˜
Q) ˜
x(t) + 2 ˜
x
T
(t) ˜
P i ˜
A hi ˜
x h
+ 2 ˜
x
T
(t) ˜
P i ˜
B i w(t) − ˜
x
T
h Q ˜
x h − β ˜
x
T
(t) ˜
P i ˜
x(t)
− ξ
2
w
T
(t)w(t) + ˜
x
T
(t) ˜
C
T
i
˜
C i ˜
x(t) + 2 ˜
x
T
(t) ˜
C
T
i
˜
D i w(t)
+ 2 ˜
x
T
(t) ˜
C
T
i
˜
C hi ˜
x h + w
T
(t) ˜
D
T
i
˜
D i w(t) + 2w
T
(t) ˜
D
T
i
˜
C hi ˜
x h + ˜
x
T
h
˜
C
T
hi
˜
C hi ˜
x h
= θ
T
(t)) i θ(t),
(6.14)
where
θ(t) =
˜
x
T
(t) w
T
(t) ˜
x
T
h
T ,
i =
⎡
⎢
⎢
⎣
˜
P i ˜
A i + ˜
A
T
i
˜
P i +
N
j=1 π i j ˜
P j + ˜
Q − β ˜
P i ˜
P i ˜
B i ˜
P i ˜
A hi ˜
C
T
i
∗
− ξ
2 I 0
˜
D
T
i
∗
∗
− Q ˜
C
T
hi
∗
∗
∗ − I
⎤
⎥
⎥
⎦ .
We define ˜
P i = diag{P i , P i , P i }, ˜
Q =
⎡
⎣
Q 11 Q 12 Q 13
∗ Q 22 Q 23
∗ ∗ Q 33
⎤
⎦ , where P i > 0 is modedependent symmetric matrix, Q ss > 0, s = 1, 2, 3 is symmetric and Q 12 , Q 13 , Q 23
are full rank matrices.
We can see that i < 0 amounts to the following relationship:
i + i < 0,
(6.15)