

6.1 Robust FD Filter Design for Multi-model Jumping System
97
˙
x f (t) = A w x f (t) + B w f (t),
r f (t) = C w x f (t) + D w f (t).
(6.4)
From (6.4), we can find that the reference residual r e f (t) is just related to the fault
signals f (t) and can be decoupled from u(t) and ω(t). Besides, the purpose of this
paper is to get an optimal FD filter which can minimize the difference between the
reference model and the FD filter.
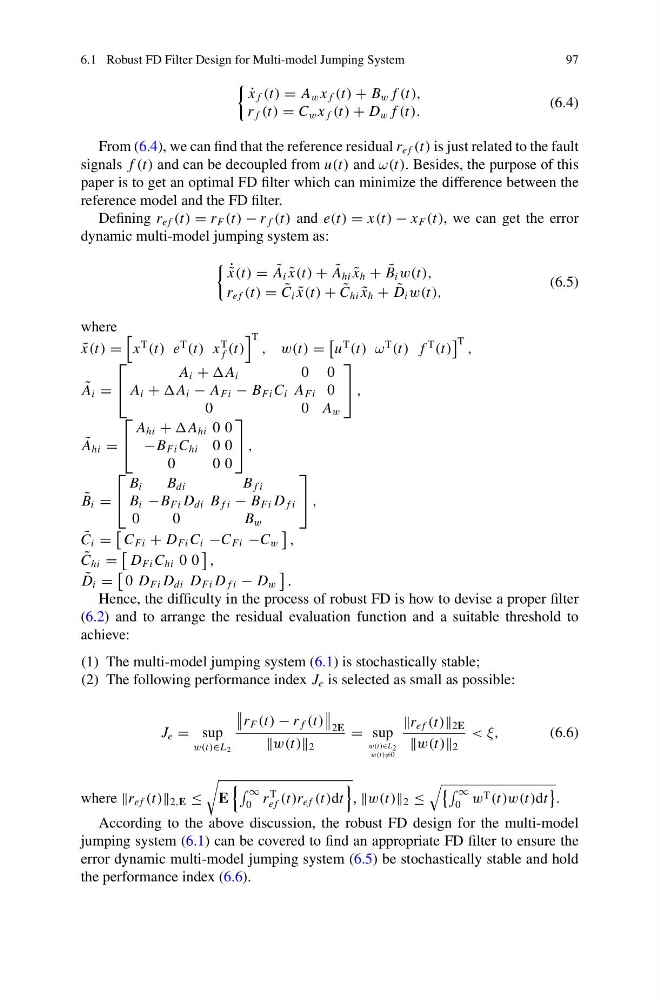
Defining r e f (t) = r F (t) − r f (t) and e(t) = x(t) − x F (t), we can get the error
dynamic multi-model jumping system as:
˙ ˜
x(t) = ˜
A i ˜
x(t) + ˜
A hi ˜
x h + ˜
B i w(t),
r e f (t) = ˜
C i ˜
x(t) + ˜
C hi ˜
x h + ˜
D i w(t),
(6.5)
where
˜
x(t) =
x
T
(t) e
T
(t) x
T
f (t)
T , w(t) =
u
T
(t) ω
T
(t) f
T
(t)
T ,
˜
A i =
⎡
⎣
A i + A i
0 0
A i + A i − A Fi − B Fi C i A Fi 0
0
0 A w
⎤
⎦ ,
˜
A hi =
⎡
⎣
A hi + A hi 0 0
−B Fi C hi 0 0
0
00
⎤
⎦ ,
˜
B i =
⎡
⎣
B i
B di
B f i
B i −B Fi D di B f i − B Fi D f i
0
0
B w
⎤
⎦ ,
˜
C i =
C Fi + D Fi C i −C Fi −C w
,
˜
C hi =
D Fi C hi 0 0
,
˜
D i =
0 D Fi D di D Fi D f i − D w
.
Hence, the difficulty in the process of robust FD is how to devise a proper filter
(6.2) and to arrange the residual evaluation function and a suitable threshold to
achieve:
(1) The multi-model jumping system (6.1) is stochastically stable;
(2) The following performance index J e is selected as small as possible:
J e = sup
w(t)∈L 2
r F (t) − r f (t)
2E
w(t) 2
= sup
w(t)∈L 2
w(t) =0
r e f (t) 2E
w(t) 2
< ξ,
(6.6)
where r e f (t) 2,E ≤
E
∞
0 r
T
e f (t)r e f (t)dt
, w(t) 2 ≤
∞
0 w T (t)w(t)dt
.
According to the above discussion, the robust FD design for the multi-model
jumping system (6.1) can be covered to find an appropriate FD filter to ensure the
error dynamic multi-model jumping system (6.5) be stochastically stable and hold
the performance index (6.6).