

5.4 Conclusions
93
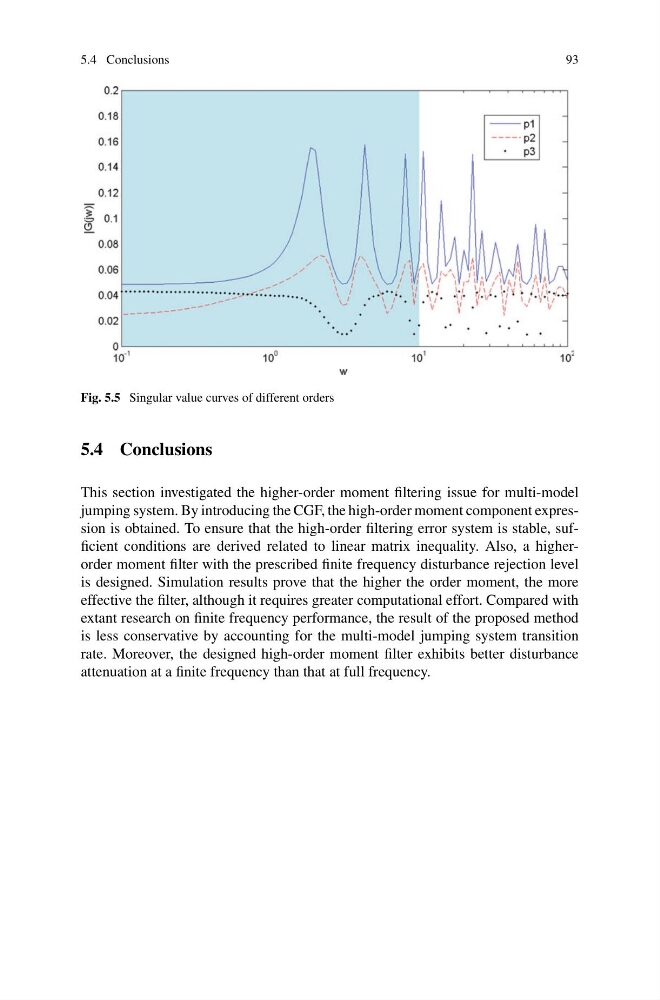
Fig. 5.5 Singular value curves of different orders
5.4 Conclusions
This section investigated the higher-order moment filtering issue for multi-model
jumping system. By introducing the CGF, the high-order moment component expression is obtained. To ensure that the high-order filtering error system is stable, sufficient conditions are derived related to linear matrix inequality. Also, a higherorder moment filter with the prescribed finite frequency disturbance rejection level
is designed. Simulation results prove that the higher the order moment, the more
effective the filter, although it requires greater computational effort. Compared with
extant research on finite frequency performance, the result of the proposed method
is less conservative by accounting for the multi-model jumping system transition
rate. Moreover, the designed high-order moment filter exhibits better disturbance
attenuation at a finite frequency than that at full frequency.