

15.1 Derivation and Properties of the RPA Equations
225
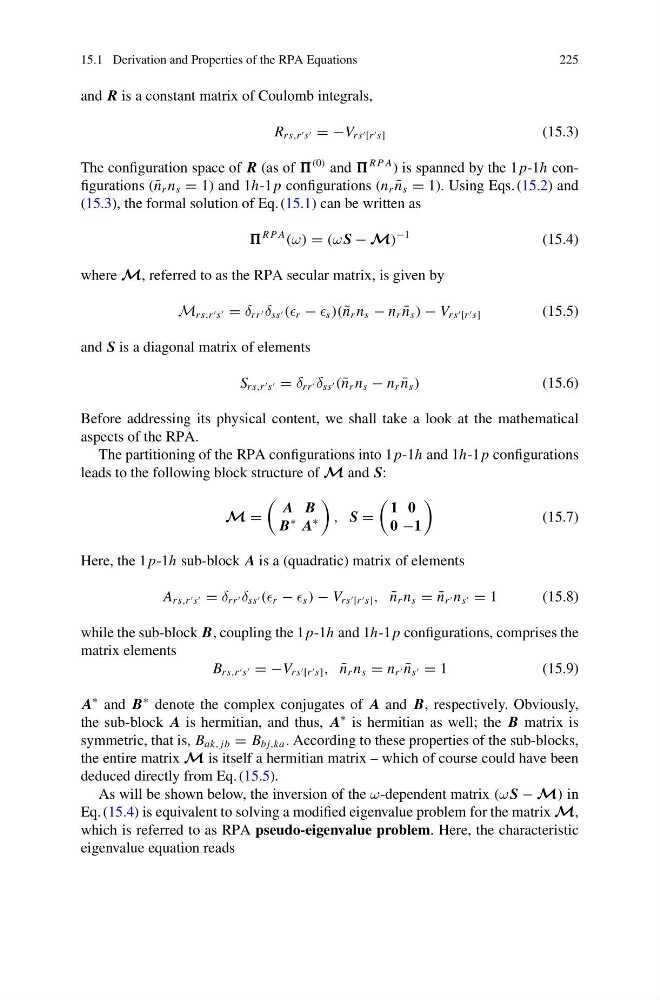
and R is a constant matrix of Coulomb integrals,
R rs,r s = −V rs [r s]
(15.3)
The configuration space of R (as of
(0) and
R P A ) is spanned by the 1 p-1h configurations ( ¯
n r n s = 1) and 1h-1 p configurations (n r ¯
n s = 1). Using Eqs. (15.2) and
(15.3), the formal solution of Eq. (15.1) can be written as
R P A
(ω) = (ω S − M)
−1
(15.4)
where M, referred to as the RPA secular matrix, is given by
M rs,r s = δ rr δ ss ( r − s )( ¯
n r n s − n r ¯
n s ) − V rs [r s]
(15.5)
and S is a diagonal matrix of elements
S rs,r s = δ rr δ ss ( ¯
n r n s − n r ¯
n s )
(15.6)
Before addressing its physical content, we shall take a look at the mathematical
aspects of the RPA.
The partitioning of the RPA configurations into 1 p-1h and 1h-1 p configurations
leads to the following block structure of M and S:
M =
A B
B
∗ A
∗
, S =
1 0
0 −1
(15.7)
Here, the 1 p-1h sub-block A is a (quadratic) matrix of elements
A rs,r s = δ rr δ ss ( r − s ) − V rs [r s] , ¯
n r n s = ¯
n r n s = 1
(15.8)
while the sub-block B, coupling the 1 p-1h and 1h-1 p configurations, comprises the
matrix elements
B rs,r s = −V rs [r s] , ¯
n r n s = n r ¯
n s = 1
(15.9)
A
∗ and B
∗ denote the complex conjugates of A and B, respectively. Obviously,
the sub-block A is hermitian, and thus, A
∗ is hermitian as well; the B matrix is
symmetric, that is, B ak, jb = B bj,ka . According to these properties of the sub-blocks,
the entire matrix M is itself a hermitian matrix – which of course could have been
deduced directly from Eq. (15.5).
As will be shown below, the inversion of the ω-dependent matrix (ω S − M) in
Eq. (15.4) is equivalent to solving a modified eigenvalue problem for the matrix M,
which is referred to as RPA pseudo-eigenvalue problem. Here, the characteristic
eigenvalue equation reads