

198
M. Wu et al.
Candidate points
Reference standard
h2
h1
(a)
(b)
(c)
(d)
(e)
(f)
(g)
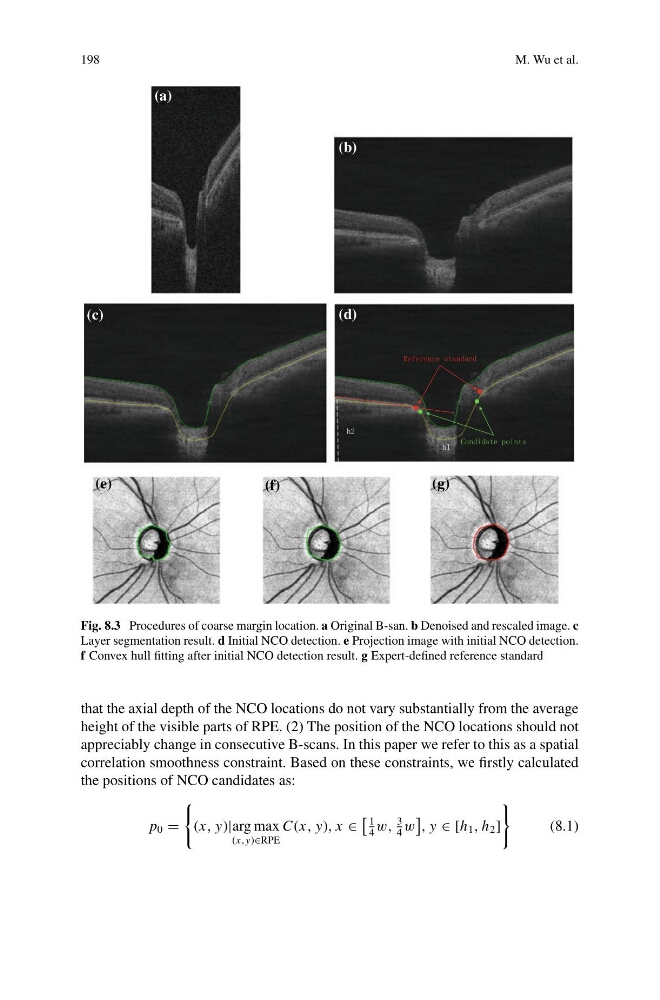
Fig. 8.3 Procedures of coarse margin location. a Original B-san. b Denoised and rescaled image. c
Layer segmentation result. d Initial NCO detection. e Projection image with initial NCO detection.
f Convex hull fitting after initial NCO detection result. g Expert-defined reference standard
that the axial depth of the NCO locations do not vary substantially from the average
height of the visible parts of RPE. (2) The position of the NCO locations should not
appreciably change in consecutive B-scans. In this paper we refer to this as a spatial
correlation smoothness constraint. Based on these constraints, we firstly calculated
the positions of NCO candidates as:
p 0
(x, y)|arg max
(x,y)∈RPE
C(x, y), x ∈
1
4
w,
3
4
w
, y ∈ [h 1 , h 2 ]
(8.1)