

100
Z. Liu et al.
distribution of oxygen consumption variables into several feature spaces with a
simpler distribution of oxygen consumption variables, to facilitate the model to fit
the data distribution. Here, the idea of Classification And Regression Tree (CART)
[13] generation algorithm is used to divide the feature space.
Given the training data set based on the feature variable X= [x
(1) , . . . , x
(12) ] and the
oxygen consumption variable Y:D = {(x 1 , y 1 ), (x 2 , y 2 ), . . . , (x N , y N )}, and feature
variable X constitutes feature space S. The i-th feature variable x
(i) and its value s i
can be selected as division variable and critical point, and define two subspaces:
S 1 (i, s i ) = {x|x
(i)
< s i }, S 2 (i, s i ) = {x|x
(i)
≥ s i }
(1)
Then find the optimal division variable and optimal critical point based on the
Minimum Square Error Principle (MSEP), namely solve:
i, s i = arg min
i,s i
⎡
⎣
x j ∈S 1 (i,s i )
(y j − c 1 )
2
+
x j ∈S 2 (i,s i )
(y j − c 2 )
2
⎤
⎦
(2)
where, c m is the mean value of the output variable y in S m , namely
c m = ave(y i |x i ∈ S m ), m = 1, 2
( 3 )
where, ave() is the mean calculation function. Repeat the above process for each
subspace S m , and the recursion depth keeps increasing, and the number of samples
contained in each subspace keeps decreasing. Finally, the feature space S is divided
into M subspaces, and the Mean Square Errors (MSE) of the output variable in each
subspace are e1,. . . , e M .
e m = ave((y i − c m )
2
|x i ∈ R m ), m = 1, . . . , M
(4)
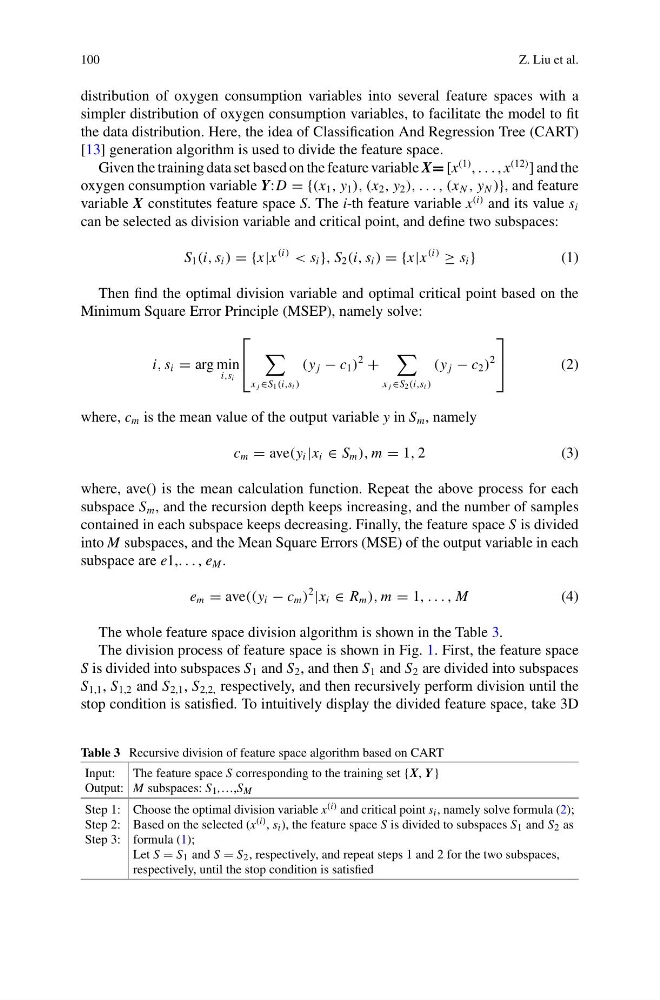
The whole feature space division algorithm is shown in the Table 3.
The division process of feature space is shown in Fig. 1. First, the feature space
S is divided into subspaces S 1 and S 2 , and then S 1 and S 2 are divided into subspaces
S 1,1 , S 1,2 and S 2,1 , S 2,2, respectively, and then recursively perform division until the
stop condition is satisfied. To intuitively display the divided feature space, take 3D
Table 3 Recursive division of feature space algorithm based on CART
Input:
Output:
The feature space S corresponding to the training set {X, Y}
M subspaces: S 1 ,…,S M
Step 1:
Step 2:
Step 3:
Choose the optimal division variable x (i) and critical point s i , namely solve formula (2);
Based on the selected (x (i) , s i ), the feature space S is divided to subspaces S 1 and S 2 as
formula (1);
Let S = S 1 and S = S 2 , respectively, and repeat steps 1 and 2 for the two subspaces,
respectively, until the stop condition is satisfied