

58
2 The Discrete Spectrum and the Continuum
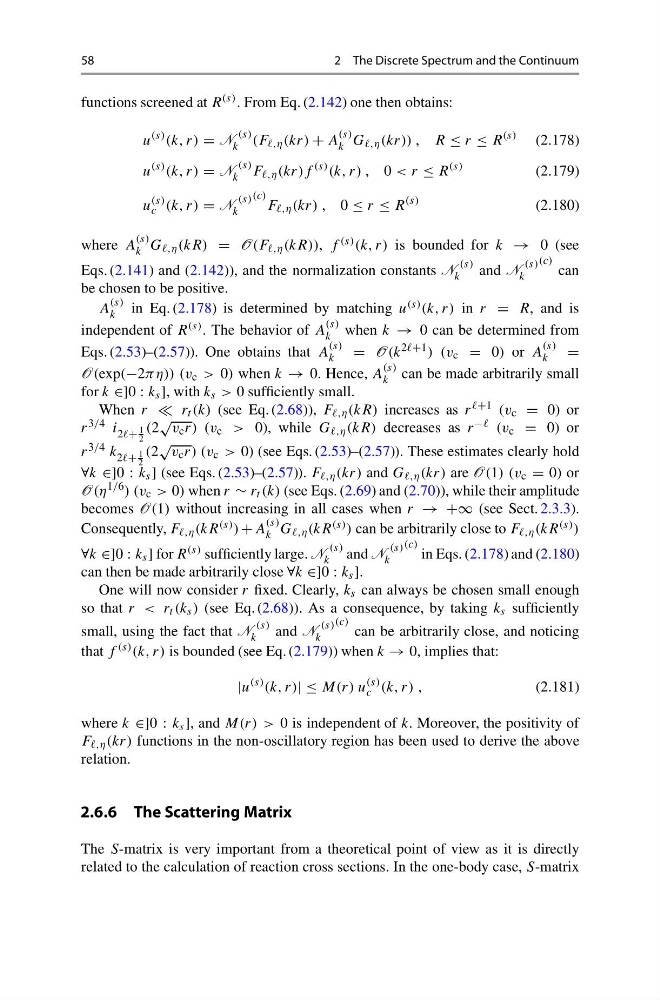
functions screened at R (s) . From Eq. (2.142) one then obtains:
u
(s) (k, r) = N
(s)
k (F ,η (kr) + A
(s)
k G ,η (kr)) , R ≤ r ≤ R
(s)
(2.178)
u
(s) (k, r) = N
(s)
k F ,η (kr)f
(s) (k, r) , 0 < r ≤ R
(s)
(2.179)
u
(s)
c (k, r) = N
(s)
k
(c)
F ,η (kr) , 0 ≤ r ≤ R
(s)
(2.180)
where A
(s)
k G ,η (kR) = O(F ,η (kR)), f (s) (k, r) is bounded for k → 0 (see
Eqs. (2.141) and (2.142)), and the normalization constants N
(s)
k
and N
(s)
k
(c)
can
be chosen to be positive.
A
(s)
k in Eq. (2.178) is determined by matching u (s) (k, r) in r = R, and is
independent of R (s) . The behavior of A
(s)
k when k → 0 can be determined from
Eqs. (2.53)–(2.57)). One obtains that A
(s)
k
= O(k 2 ) (v c = 0) or A
(s)
k
=
O(exp(−2πη)) (v c > 0) when k → 0. Hence, A
(s)
k can be made arbitrarily small
for k ∈]0 : k s ], with k s > 0 sufficiently small.
When r r t (k) (see Eq. (2.68)), F ,η (kR) increases as r (v c = 0) or
r 3/4 i 2
1
2
(2
√
v c r) (v c > 0), while G ,η (kR) decreases as r − (v c = 0) or
r 3/4 k 2
1
2
(2
√
v c r) (v c > 0) (see Eqs. (2.53)–(2.57)). These estimates clearly hold
∀k ∈]0 : k s ] (see Eqs. (2.53)–(2.57)). F ,η (kr) and G ,η (kr) are O(1) (v c = 0) or
O(η 1/6 ) (v c > 0) when r ∼ r t (k) (see Eqs. (2.69) and (2.70)), while their amplitude
becomes O(1) without increasing in all cases when r → +∞ (see Sect. 2.3.3).
Consequently, F ,η (kR (s) ) + A
(s)
k G ,η (kR (s) ) can be arbitrarily close to F ,η (kR (s) )
∀k ∈]0 : k s ] for R (s) sufficiently large. N
(s)
k
and N
(s)
k
(c)
in Eqs. (2.178) and (2.180)
can then be made arbitrarily close ∀k ∈]0 : k s ].
One will now consider r fixed. Clearly, k s can always be chosen small enough
so that r < r t (k s ) (see Eq. (2.68)). As a consequence, by taking k s sufficiently
small, using the fact that N
(s)
k
and N
(s)
k
(c)
can be arbitrarily close, and noticing
that f (s) (k, r) is bounded (see Eq. (2.179)) when k → 0, implies that:
|u
(s) (k, r)| ≤ M(r) u
(s)
c (k, r) ,
(2.181)
where k ∈]0 : k s ], and M(r) > 0 is independent of k. Moreover, the positivity of
F ,η (kr) functions in the non-oscillatory region has been used to derive the above
relation.
2.6.6 The Scattering Matrix
The S-matrix is very important from a theoretical point of view as it is directly
related to the calculation of reaction cross sections. In the one-body case, S-matrix