

1.3 The World Function and Deviation Equations
11
to the neighbouring screen corresponds to r → r + dr and this corresponds to
ζ → ζ + dζ = ζ where
ζ
= (1 − ρ dr) ζ − σ ¯
ζ dr ,
(1.59)
on account of (1.51). We assume that the disk is circular so that ζ = e i φ , with
0 ≤ φ < 2 π. With this substituted into (1.59), ζ specifies points on the boundary
of the shadow relative to points on the boundary of the disk. With ρ = −θ − i ω we
consider first the case ω = 0 = σ . Now ζ = (1 + θ dr)ζ and thus the shadow is
a circle with a radius larger than the disk radius if θ > 0, or smaller than the disk
radius if θ < 0. Hence we interpret the scalar θ to represent the expansion of the
congruence if θ > 0 or the contraction of the congruence if θ < 0. Considering next
the case θ = 0 = σ we have from (1.59), ζ = (1 + i ω dr) ζ = e i ω dr ζ , neglecting
O(dr 2 )-terms. In this case the shadow is a circle but the points on the boundary
of the shadow are rotated relative to points on the boundary of the disk through a
small angle ω dr. Hence the scalar ω is interpreted as the twist of the congruence.
Finally the case θ = 0 = ω results in (1.59) becoming ζ = e i φ − σ e −i φ dr.
Now the shadow is approximately elliptical with semi-major and semi-minor axes
corresponding to φ given by e 2 i φ = ±(σ/ ¯
σ ) 1/2 . The lengths of these axes are then
l ± = 1 ± |σ | dr and their ratio is thus l + /l − = 1 + 2 |σ | dr approximately. The area
of the shadow is the same as the area of the disk, neglecting O(dr 2 )-terms, and thus
we interpret |σ | as the shear of the congruence. We note that σ is usually referred
to as the complex shear of the congruence.
The theory of null geodesic congruences originated in [5, 6] while the presentation given here is strongly influenced by the elegant treatment by Pirani [7] (see also
[8]).
1.3
The World Function and Deviation Equations
Our study of congruences above has involved in particular the deviation of
neighbouring lines of a congruence. The concept of deviation can be generalised
to time-like curves Y (t) and X(˜ t) (say) where the parameters t and ˜
t along the
curves are no longer necessarily proper time or arc length.
As sketched in Fig. 1.2, we assume that there exists a unique geodesic Z joining
two points x ∈ X and y ∈ Y on the two curves. Along this geodesic we introduce
the so-called world function as an integral
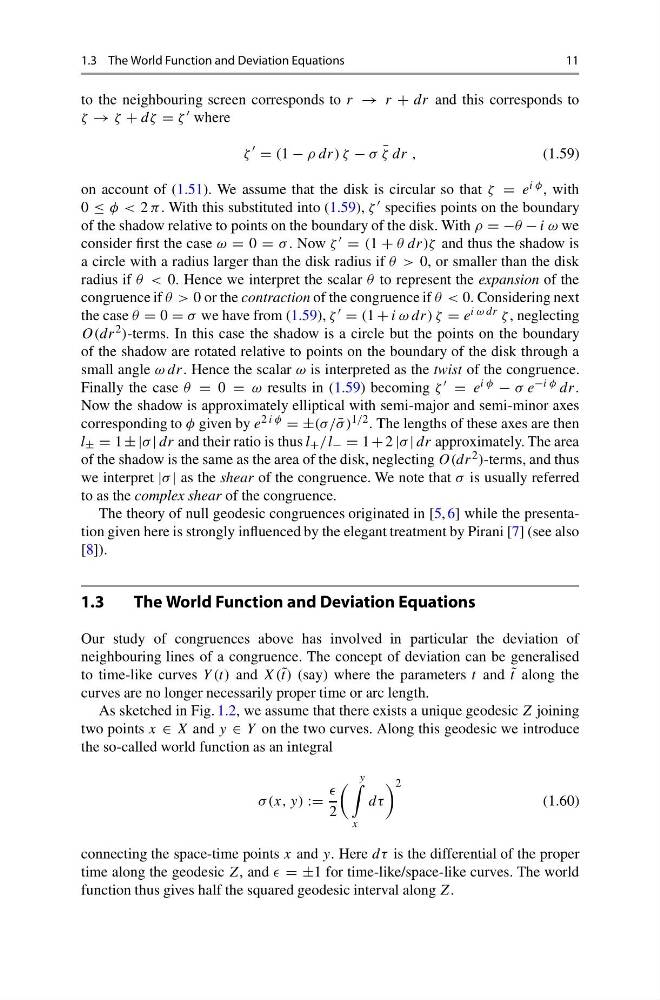
σ (x, y) :=
2
y
x
dτ
2
(1.60)
connecting the space-time points x and y. Here dτ is the differential of the proper
time along the geodesic Z, and = ±1 for time-like/space-like curves. The world
function thus gives half the squared geodesic interval along Z.