

192
5 Optimization Algorithm and RFID System Physical Anti-Collision
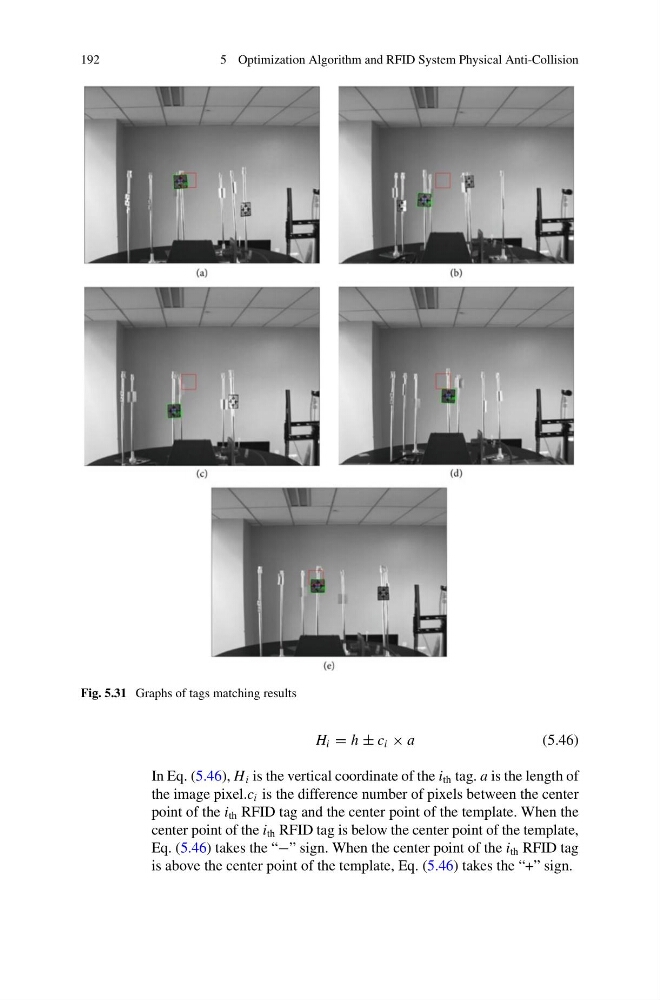
Fig. 5.31 Graphs of tags matching results
H i = h ± c i × a
(5.46)
In Eq. (5.46), H i is the vertical coordinate of the i th tag. a is the length of
the image pixel.c i is the difference number of pixels between the center
point of the i th RFID tag and the center point of the template. When the
center point of the i th RFID tag is below the center point of the template,
Eq. (5.46) takes the “−” sign. When the center point of the i th RFID tag
is above the center point of the template, Eq. (5.46) takes the “+” sign.