

178
5 Optimization Algorithm and RFID System Physical Anti-Collision
Fig. 5.17 Procedure of tags’
position locating
In the part of feature extraction and recognition, we get the location of tags based
on shape feature, as shown in Fig. 5.17.
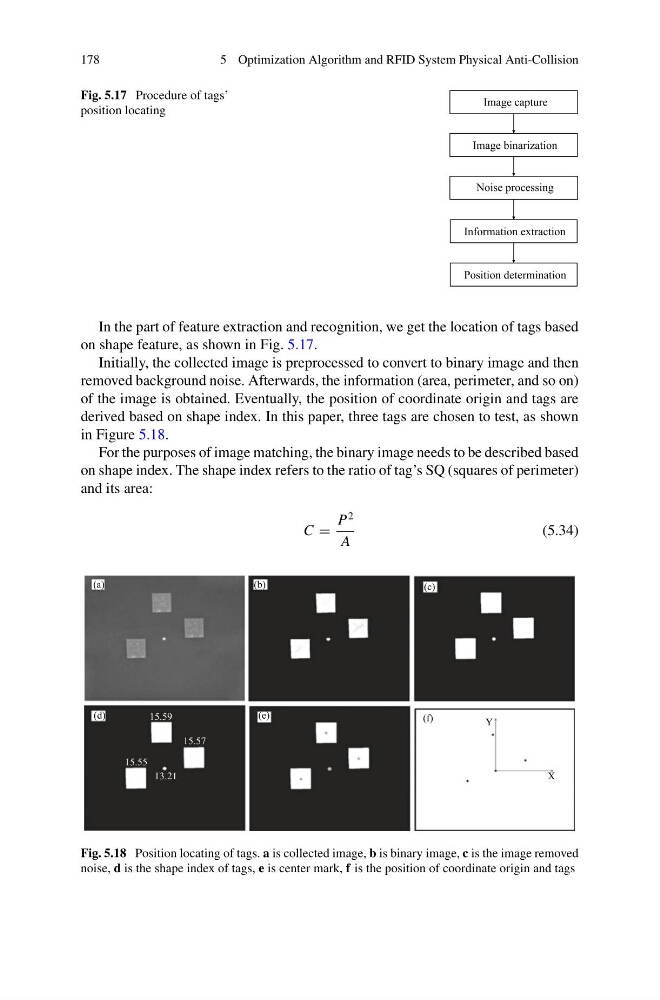
Initially, the collected image is preprocessed to convert to binary image and then
removed background noise. Afterwards, the information (area, perimeter, and so on)
of the image is obtained. Eventually, the position of coordinate origin and tags are
derived based on shape index. In this paper, three tags are chosen to test, as shown
in Figure 5.18.
For the purposes of image matching, the binary image needs to be described based
on shape index. The shape index refers to the ratio of tag’s SQ (squares of perimeter)
and its area:
C =
P
2
A
(5.34)
Fig. 5.18 Position locating of tags. a is collected image, b is binary image, c is the image removed
noise, d is the shape index of tags, e is center mark, f is the position of coordinate origin and tags