

430
A. Prokop et al.
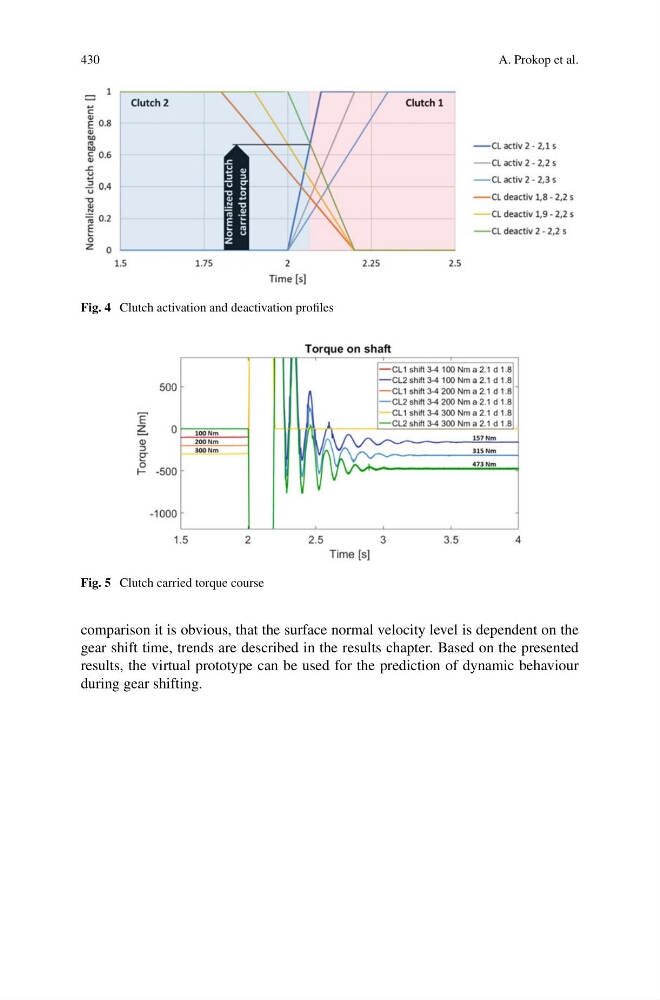
Fig. 4 Clutch activation and deactivation profiles
Fig. 5 Clutch carried torque course
comparison it is obvious, that the surface normal velocity level is dependent on the
gear shift time, trends are described in the results chapter. Based on the presented
results, the virtual prototype can be used for the prediction of dynamic behaviour
during gear shifting.