

376
S. Vlase et al.
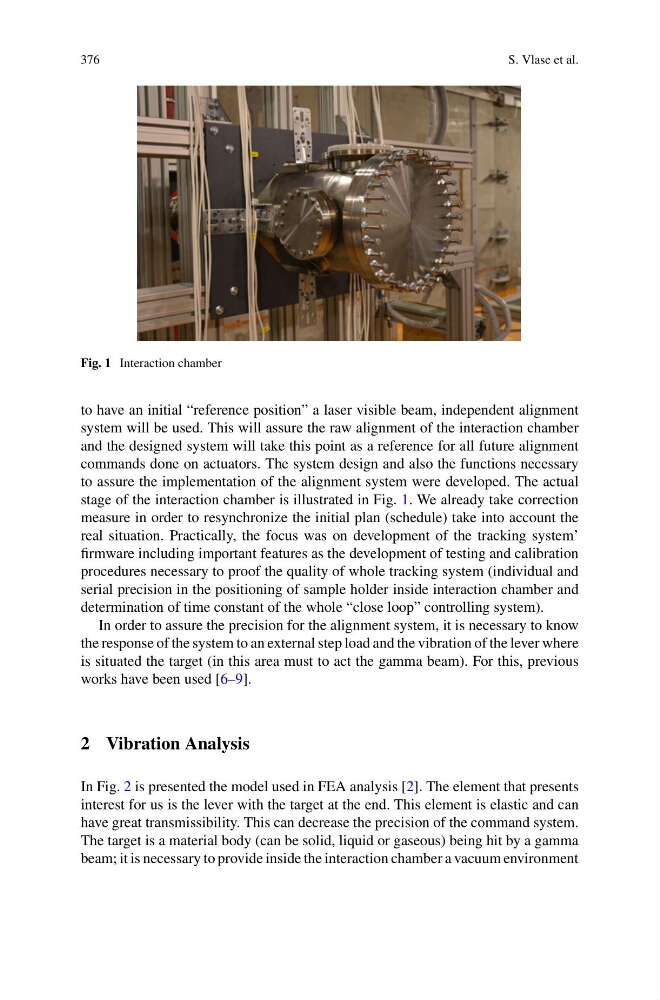
Fig. 1 Interaction chamber
to have an initial “reference position” a laser visible beam, independent alignment
system will be used. This will assure the raw alignment of the interaction chamber
and the designed system will take this point as a reference for all future alignment
commands done on actuators. The system design and also the functions necessary
to assure the implementation of the alignment system were developed. The actual
stage of the interaction chamber is illustrated in Fig. 1. We already take correction
measure in order to resynchronize the initial plan (schedule) take into account the
real situation. Practically, the focus was on development of the tracking system’
firmware including important features as the development of testing and calibration
procedures necessary to proof the quality of whole tracking system (individual and
serial precision in the positioning of sample holder inside interaction chamber and
determination of time constant of the whole “close loop” controlling system).
In order to assure the precision for the alignment system, it is necessary to know
the response of the system to an external step load and the vibration of the lever where
is situated the target (in this area must to act the gamma beam). For this, previous
works have been used [6–9].
2 Vibration Analysis
In Fig. 2 is presented the model used in FEA analysis [2]. The element that presents
interest for us is the lever with the target at the end. This element is elastic and can
have great transmissibility. This can decrease the precision of the command system.
The target is a material body (can be solid, liquid or gaseous) being hit by a gamma
beam; it is necessary to provide inside the interaction chamber a vacuum environment