

Angular Momentum About the Total Body Center of Mass Computed …
229
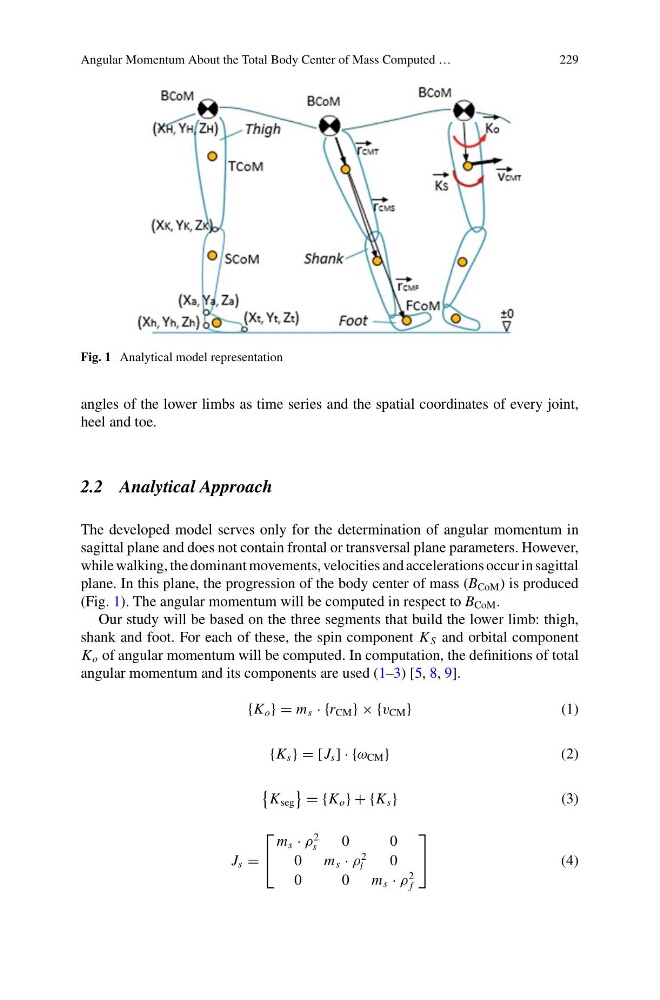
Fig. 1 Analytical model representation
angles of the lower limbs as time series and the spatial coordinates of every joint,
heel and toe.
2.2 Analytical Approach
The developed model serves only for the determination of angular momentum in
sagittal plane and does not contain frontal or transversal plane parameters. However,
while walking, the dominant movements, velocities and accelerations occur in sagittal
plane. In this plane, the progression of the body center of mass (B CoM ) is produced
(Fig. 1). The angular momentum will be computed in respect to B CoM .
Our study will be based on the three segments that build the lower limb: thigh,
shank and foot. For each of these, the spin component K S and orbital component
K o of angular momentum will be computed. In computation, the definitions of total
angular momentum and its components are used (1–3) [5, 8, 9].
{K o } = m s · {r CM } × {v CM }
(1)
{K s } = [J s ] · {ω CM }
(2)
K seg
= {K o } + {K s }
(3)
J s =
⎡
⎣
m s · ρ
2
s
0
0
0 m s · ρ
2
l
0
0
0 m s · ρ
2
f
⎤
⎦
(4)