

112
E. Chircan et al.
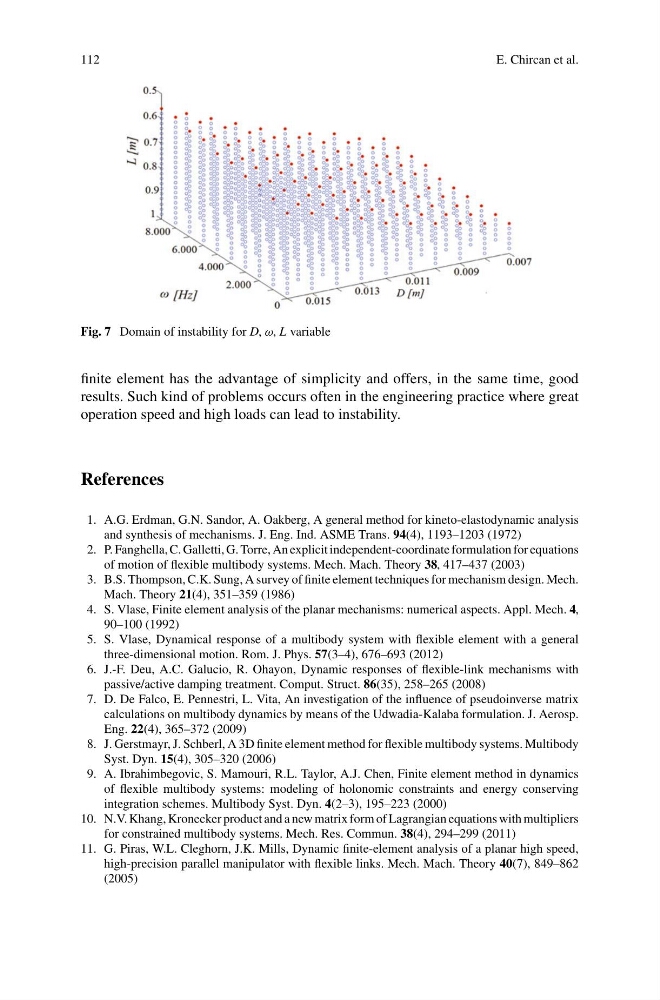
Fig. 7 Domain of instability for D, ω, L variable
finite element has the advantage of simplicity and offers, in the same time, good
results. Such kind of problems occurs often in the engineering practice where great
operation speed and high loads can lead to instability.
References
1. A.G. Erdman, G.N. Sandor, A. Oakberg, A general method for kineto-elastodynamic analysis
and synthesis of mechanisms. J. Eng. Ind. ASME Trans. 94(4), 1193–1203 (1972)
2. P. Fanghella, C. Galletti, G. Torre, An explicit independent-coordinate formulation for equations
of motion of flexible multibody systems. Mech. Mach. Theory 38, 417–437 (2003)
3. B.S. Thompson, C.K. Sung, A survey of finite element techniques for mechanism design. Mech.
Mach. Theory 21(4), 351–359 (1986)
4. S. Vlase, Finite element analysis of the planar mechanisms: numerical aspects. Appl. Mech. 4,
90–100 (1992)
5. S. Vlase, Dynamical response of a multibody system with flexible element with a general
three-dimensional motion. Rom. J. Phys. 57(3–4), 676–693 (2012)
6. J.-F. Deu, A.C. Galucio, R. Ohayon, Dynamic responses of flexible-link mechanisms with
passive/active damping treatment. Comput. Struct. 86(35), 258–265 (2008)
7. D. De Falco, E. Pennestri, L. Vita, An investigation of the influence of pseudoinverse matrix
calculations on multibody dynamics by means of the Udwadia-Kalaba formulation. J. Aerosp.
Eng. 22(4), 365–372 (2009)
8. J. Gerstmayr, J. Schberl, A 3D finite element method for flexible multibody systems. Multibody
Syst. Dyn. 15(4), 305–320 (2006)
9. A. Ibrahimbegovic, S. Mamouri, R.L. Taylor, A.J. Chen, Finite element method in dynamics
of flexible multibody systems: modeling of holonomic constraints and energy conserving
integration schemes. Multibody Syst. Dyn. 4(2–3), 195–223 (2000)
10. N.V. Khang, Kronecker product and a new matrix form of Lagrangian equations with multipliers
for constrained multibody systems. Mech. Res. Commun. 38(4), 294–299 (2011)
11. G. Piras, W.L. Cleghorn, J.K. Mills, Dynamic finite-element analysis of a planar high speed,
high-precision parallel manipulator with flexible links. Mech. Mach. Theory 40(7), 849–862
(2005)