

34 Fundamental concepts
Applying the Maxwell’s rule to the tetrahedron shown in Figure 2.2 we
have n = 6, r = 6 and j = 4. The tetrahedron truss is therefore a stiff structure
because 3j – (n + r) = 0. Unlike the Kutzbach criterion, the Maxwell’s rule
can disregard the idle degrees of freedom in this instance.
Similar to the Kutzbach criterion, the Maxwell’s rule does not take the
geometry of the assembly into consideration. It is no surprise that it can
also produce misleading results. To avoid that, a more thorough approach
has to be taken.
Consider a truss in space with n members, r supports and j spherical
joints. It is subjected to 3j arbitrary independent components of load applied
at its joints, and let these be denoted by vector f. The 3j equations of equilibrium relate the load components to the n member forces and the r reactions;
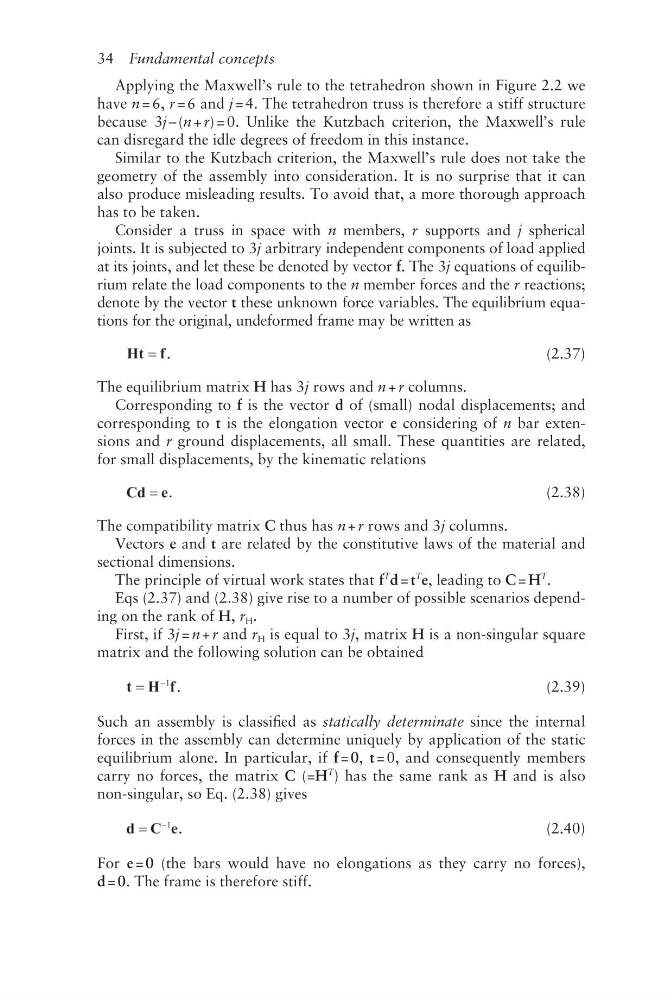
denote by the vector t these unknown force variables. The equilibrium equations for the original, undeformed frame may be written as
.
(2.37)
The equilibrium matrix H has 3j rows and n + r columns.
Corresponding to f is the vector d of (small) nodal displacements; and
corresponding to t is the elongation vector e considering of n bar extensions and r ground displacements, all small. These quantities are related,
for small displacements, by the kinematic relations
.
(2.38)
The compatibility matrix C thus has n + r rows and 3j columns.
Vectors e and t are related by the constitutive laws of the material and
sectional dimensions.
The principle of virtual work states that f
T
d = t
T
e, leading to C = H
T
.
Eqs (2.37) and (2.38) give rise to a number of possible scenarios depending on the rank of H, r H .
First, if 3j = n + r and r H is equal to 3j, matrix H is a non- singular square
matrix and the following solution can be obtained
.
(2.39)
Such an assembly is classified as statically determinate since the internal
forces in the assembly can determine uniquely by application of the static
equilibrium alone. In particular, if f = 0, t = 0, and consequently members
carry no forces, the matrix C (=H
T
) has the same rank as H and is also
non- singular, so Eq. (2.38) gives
.
(2.40)
For e = 0 (the bars would have no elongations as they carry no forces),
d = 0. The frame is therefore stiff.