

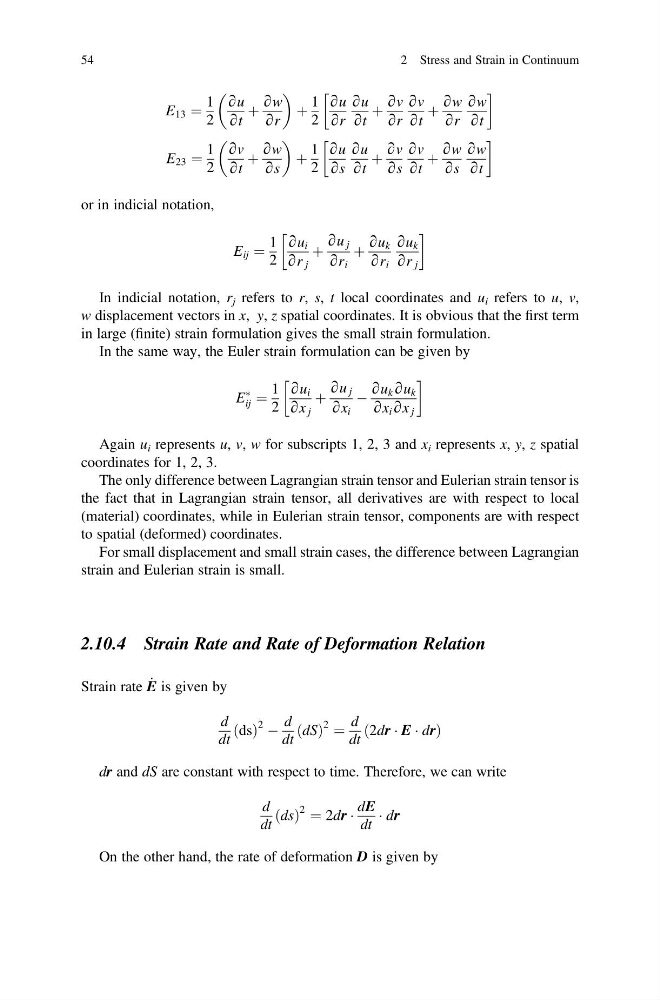
E 13 ¼
1
2
∂u
∂t
þ
∂w
∂r
þ
1
2
∂u
∂r
∂u
∂t
þ
∂v
∂r
∂v
∂t
þ
∂w
∂r
∂w
∂t
!
E 23 ¼
1
2
∂v
∂t
þ
∂w
∂s
þ
1
2
∂u
∂s
∂u
∂t
þ
∂v
∂s
∂v
∂t
þ
∂w
∂s
∂w
∂t
!
or in indicial notation,
E ij ¼
1
2
∂u i
∂r j
þ
∂u j
∂r i
þ
∂u k
∂r i
∂u k
∂r j
!
In indicial notation, r j refers to r, s, t local coordinates and u i refers to u, v,
w displacement vectors in x, y, z spatial coordinates. It is obvious that the first term
in large (finite) strain formulation gives the small strain formulation.
In the same way, the Euler strain formulation can be given by
E
Ã
ij ¼
1
2
∂u i
∂x j
þ
∂u j
∂x i
À
∂u k ∂u k
∂x i ∂x j
!
Again u i represents u, v, w for subscripts 1, 2, 3 and x i represents x, y, z spatial
coordinates for 1, 2, 3.
The only difference between Lagrangian strain tensor and Eulerian strain tensor is
the fact that in Lagrangian strain tensor, all derivatives are with respect to local
(material) coordinates, while in Eulerian strain tensor, components are with respect
to spatial (deformed) coordinates.
For small displacement and small strain cases, the difference between Lagrangian
strain and Eulerian strain is small.
2.10.4 Strain Rate and Rate of Deformation Relation
Strain rate _
E is given by
d
dt
ds
ð Þ
2 À
d
dt
dS
ð Þ
2 ¼
d
dt
2dr Á E Á dr
ð
Þ
dr and dS are constant with respect to time. Therefore, we can write
d
dt
ds
ð Þ
2 ¼ 2dr Á
dE
dt
Á dr
On the other hand, the rate of deformation D is given by
54
2 Stress and Strain in Continuum
1
2
∂u
∂t
þ
∂w
∂r
þ
1
2
∂u
∂r
∂u
∂t
þ
∂v
∂r
∂v
∂t
þ
∂w
∂r
∂w
∂t
!
E 23 ¼
1
2
∂v
∂t
þ
∂w
∂s
þ
1
2
∂u
∂s
∂u
∂t
þ
∂v
∂s
∂v
∂t
þ
∂w
∂s
∂w
∂t
!
or in indicial notation,
E ij ¼
1
2
∂u i
∂r j
þ
∂u j
∂r i
þ
∂u k
∂r i
∂u k
∂r j
!
In indicial notation, r j refers to r, s, t local coordinates and u i refers to u, v,
w displacement vectors in x, y, z spatial coordinates. It is obvious that the first term
in large (finite) strain formulation gives the small strain formulation.
In the same way, the Euler strain formulation can be given by
E
Ã
ij ¼
1
2
∂u i
∂x j
þ
∂u j
∂x i
À
∂u k ∂u k
∂x i ∂x j
!
Again u i represents u, v, w for subscripts 1, 2, 3 and x i represents x, y, z spatial
coordinates for 1, 2, 3.
The only difference between Lagrangian strain tensor and Eulerian strain tensor is
the fact that in Lagrangian strain tensor, all derivatives are with respect to local
(material) coordinates, while in Eulerian strain tensor, components are with respect
to spatial (deformed) coordinates.
For small displacement and small strain cases, the difference between Lagrangian
strain and Eulerian strain is small.
2.10.4 Strain Rate and Rate of Deformation Relation
Strain rate _
E is given by
d
dt
ds
ð Þ
2 À
d
dt
dS
ð Þ
2 ¼
d
dt
2dr Á E Á dr
ð
Þ
dr and dS are constant with respect to time. Therefore, we can write
d
dt
ds
ð Þ
2 ¼ 2dr Á
dE
dt
Á dr
On the other hand, the rate of deformation D is given by
54
2 Stress and Strain in Continuum