

E xy ¼
1
2
γ xy
As a result, the first matrix is the strain matrix and the second matrix is the rotation
matrix:
Ω xy ¼
1
2
∂u
∂y
À
∂v
∂x
Ω yx ¼
1
2
∂v
∂x
À
∂u
∂y
¼ ÀΩ xy
As a result, the Jacobian matrix can be written as
J ¼
E xx E xy
E yx E yy
!
þ
0 Ω xy
Ω yx
0
!
In our stress and strain definitions, the first subscript defines the plane and the
second subscript defines the direction. Now we can show that the strain matrix leads
to deformations (shape change), and the rotation matrix leads to rigid body motion
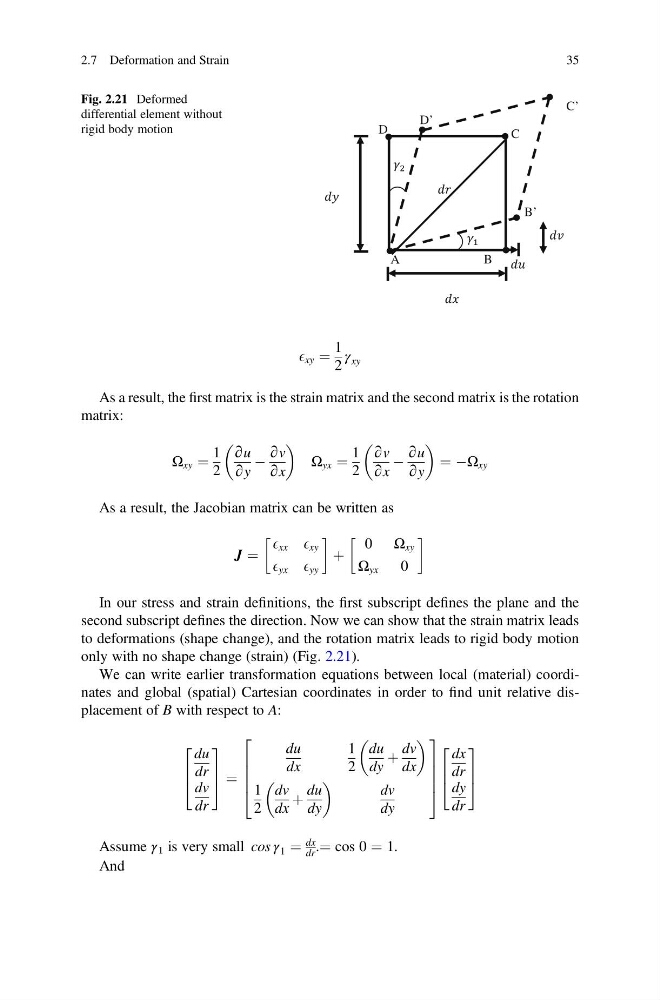
only with no shape change (strain) (Fig. 2.21).
We can write earlier transformation equations between local (material) coordinates and global (spatial) Cartesian coordinates in order to find unit relative displacement of B with respect to A:
du
dr
dv
dr
2
6
4
3
7
5 ¼
du
dx
1
2
du
dy
þ
dv
dx
1
2
dv
dx
þ
du
dy
dv
dy
2
6
6
6
4
3
7
7
7
5
dx
dr
dy
dr
2
6
4
3
7
5
Assume γ 1 is very small cos γ 1 ¼
dx
dr .¼ cos 0 ¼ 1.
And
A
B
D
D’
C
C’
B’
Fig. 2.21 Deformed
differential element without
rigid body motion
2.7 Deformation and Strain
35
1
2
γ xy
As a result, the first matrix is the strain matrix and the second matrix is the rotation
matrix:
Ω xy ¼
1
2
∂u
∂y
À
∂v
∂x
Ω yx ¼
1
2
∂v
∂x
À
∂u
∂y
¼ ÀΩ xy
As a result, the Jacobian matrix can be written as
J ¼
E xx E xy
E yx E yy
!
þ
0 Ω xy
Ω yx
0
!
In our stress and strain definitions, the first subscript defines the plane and the
second subscript defines the direction. Now we can show that the strain matrix leads
to deformations (shape change), and the rotation matrix leads to rigid body motion
only with no shape change (strain) (Fig. 2.21).
We can write earlier transformation equations between local (material) coordinates and global (spatial) Cartesian coordinates in order to find unit relative displacement of B with respect to A:
du
dr
dv
dr
2
6
4
3
7
5 ¼
du
dx
1
2
du
dy
þ
dv
dx
1
2
dv
dx
þ
du
dy
dv
dy
2
6
6
6
4
3
7
7
7
5
dx
dr
dy
dr
2
6
4
3
7
5
Assume γ 1 is very small cos γ 1 ¼
dx
dr .¼ cos 0 ¼ 1.
And
A
B
D
D’
C
C’
B’
Fig. 2.21 Deformed
differential element without
rigid body motion
2.7 Deformation and Strain
35